

70
5 Rotation of a Dipole
E(rat)
p
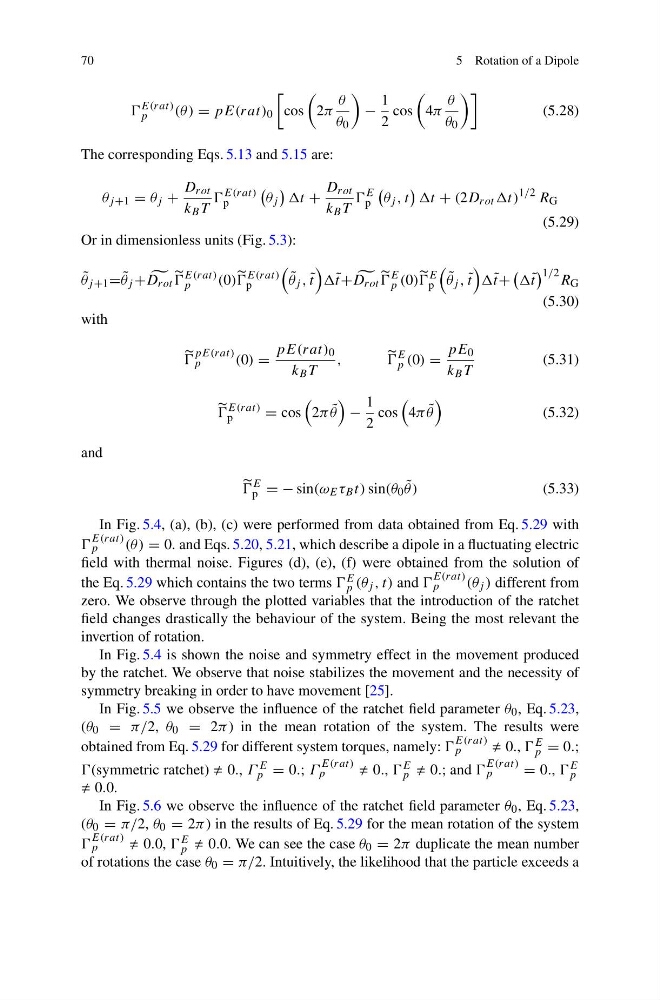
(θ ) = pE(rat) 0
cos
2π
θ
θ 0
−
1
2
cos
4π
θ
θ 0
(5.28)
The corresponding Eqs. 5.13 and 5.15 are:
θ j +1 = θ j +
D rot
k B T
E(rat)
p
θ j
t +
D rot
k B T
E
p
θ j , t
t + (2D rot t)
1/2 R G
(5.29)
Or in dimensionless units (Fig. 5.3):
˜
θ j +1 = ˜
θ j +
D rot
E(rat)
p
(0)
E(rat)
p
˜
θ j , ˜
t
˜ t+
D rot
E
p (0)
E
p
˜
θ j , ˜
t
˜ t+
˜ t
1/2 R G
(5.30)
with
pE(rat)
p
(0) =
pE(rat) 0
k B T
,
E
p (0) =
pE 0
k B T
(5.31)
E(rat)
p
= cos
2π ˜
θ
−
1
2
cos
4π ˜
θ
(5.32)
and
E
p = − sin(ω E τ B t) sin(θ 0 ˜
θ)
(5.33)
In Fig. 5.4, (a), (b), (c) were performed from data obtained from Eq. 5.29 with
E(rat)
p
(θ ) = 0. and Eqs. 5.20, 5.21, which describe a dipole in a fluctuating electric
field with thermal noise. Figures (d), (e), (f) were obtained from the solution of
the Eq. 5.29 which contains the two terms E
p (θ j , t) and
E(rat)
p
(θ j ) different from
zero. We observe through the plotted variables that the introduction of the ratchet
field changes drastically the behaviour of the system. Being the most relevant the
invertion of rotation.
In Fig. 5.4 is shown the noise and symmetry effect in the movement produced
by the ratchet. We observe that noise stabilizes the movement and the necessity of
symmetry breaking in order to have movement [25].
In Fig. 5.5 we observe the influence of the ratchet field parameter θ 0 , Eq. 5.23,
(θ 0 = π/2, θ 0 = 2π ) in the mean rotation of the system. The results were
obtained from Eq. 5.29 for different system torques, namely:
E(rat)
p
0., E
p = 0.;
(symmetric ratchet) 0., Γ E
p = 0.; Γ
E(rat)
p
0., E
p 0.; and
E(rat)
p
= 0., E
p
0.0.
In Fig. 5.6 we observe the influence of the ratchet field parameter θ 0 , Eq. 5.23,
(θ 0 = π/2, θ 0 = 2π ) in the results of Eq. 5.29 for the mean rotation of the system
E(rat)
p
0.0, E
p 0.0. We can see the case θ 0 = 2π duplicate the mean number
of rotations the case θ 0 = π/2. Intuitively, the likelihood that the particle exceeds a