

4.1 Robust Finite Frequency Filter Design for Multi-model Jumping System
59
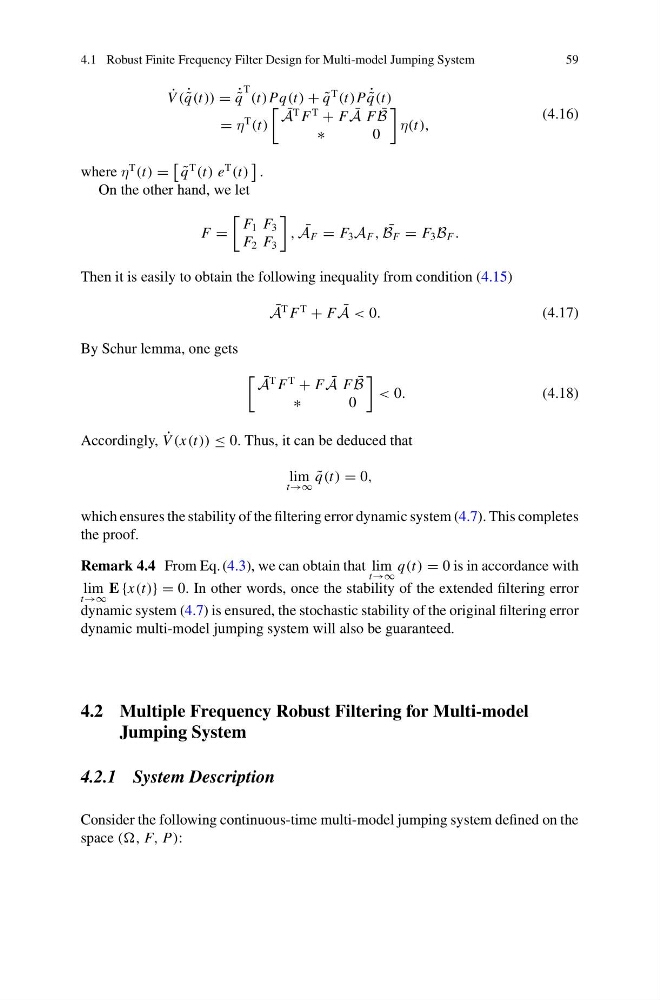
˙
V ( ˙ ˜
q(t)) = ˙ ˜
q
T (t)Pq(t) + ˜
q
T
(t)P ˙ ˜
q(t)
= η
T
(t)
¯
A
T F
T
+ F ¯
A F ¯
B
∗
0
η(t),
(4.16)
where η
T
(t) =
˜
q
T
(t) e
T
(t)
.
On the other hand, we let
F =
F 1 F 3
F 2 F 3
, ¯
A F = F 3 A F , ¯
B F = F 3 B F .
Then it is easily to obtain the following inequality from condition (4.15)
¯
A
T F
T
+ F ¯
A < 0.
(4.17)
By Schur lemma, one gets
¯
A
T F
T
+ F ¯
A F ¯
B
∗
0
< 0.
(4.18)
Accordingly, ˙
V (x(t)) ≤ 0. Thus, it can be deduced that
lim
t→∞
˜
q(t) = 0,
which ensures the stability of the filtering error dynamic system (4.7). This completes
the proof.
Remark 4.4 From Eq. (4.3), we can obtain that lim
t→∞
q(t) = 0 is in accordance with
lim
t→∞
E {x(t)} = 0. In other words, once the stability of the extended filtering error
dynamic system (4.7) is ensured, the stochastic stability of the original filtering error
dynamic multi-model jumping system will also be guaranteed.
4.2 Multiple Frequency Robust Filtering for Multi-model
Jumping System
4.2.1 System Description
Consider the following continuous-time multi-model jumping system defined on the
space ((, F, P):