

48
3 Finite-Time Robust Filtering for Multi-model Jumping System
0
5
10
15
−0.2
−0.1
0
0.1
0.2
0.3
0.4
0.5
t/s
e 1 (t)
e 2 (t)
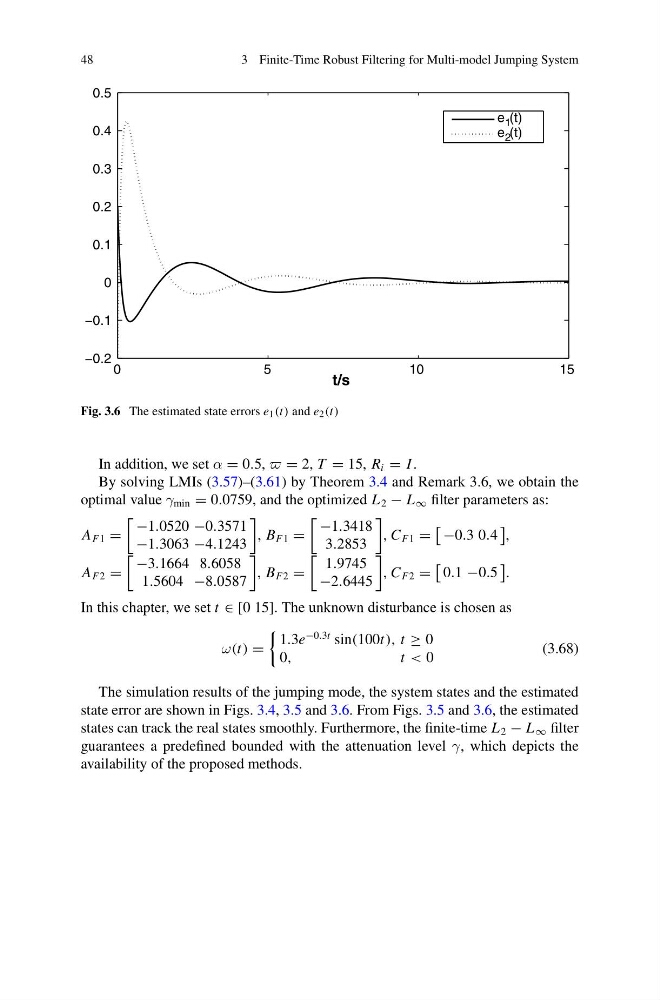
Fig. 3.6 The estimated state errors e 1 (t) and e 2 (t)
In addition, we set α = 0.5, = 2, T = 15, R i = I .
By solving LMIs (3.57)–(3.61) by Theorem 3.4 and Remark 3.6, we obtain the
optimal value γ min = 0.0759, and the optimized L 2 − L ∞ filter parameters as:
A F1 =
−1.0520 −0.3571
−1.3063 −4.1243
, B F1 =
−1.3418
3.2853
, C F1 =
−0.3 0.4
,
A F2 =
−3.1664 8.6058
1.5604 −8.0587
, B F2 =
1.9745
−2.6445
, C F2 =
0.1 −0.5
.
In this chapter, we set t ∈ [0 15]. The unknown disturbance is chosen as
ω(t) =
1.3e
−0.3t sin(100t), t ≥ 0
0,
t < 0
(3.68)
The simulation results of the jumping mode, the system states and the estimated
state error are shown in Figs. 3.4, 3.5 and 3.6. From Figs. 3.5 and 3.6, the estimated
states can track the real states smoothly. Furthermore, the finite-time L 2 − L ∞ filter
guarantees a predefined bounded with the attenuation level γ, which depicts the
availability of the proposed methods.