

44
3 Finite-Time Robust Filtering for Multi-model Jumping System
1 ≤ σ ˆ
P = min
i∈
σ min
ˆ
P i
, ¯
σ ˆ
P = max
i∈
σ max
ˆ
P i
< σ 1 ,
σ Q = max
i∈M
σ max (Q i ) ≤ σ 2
(3.66)
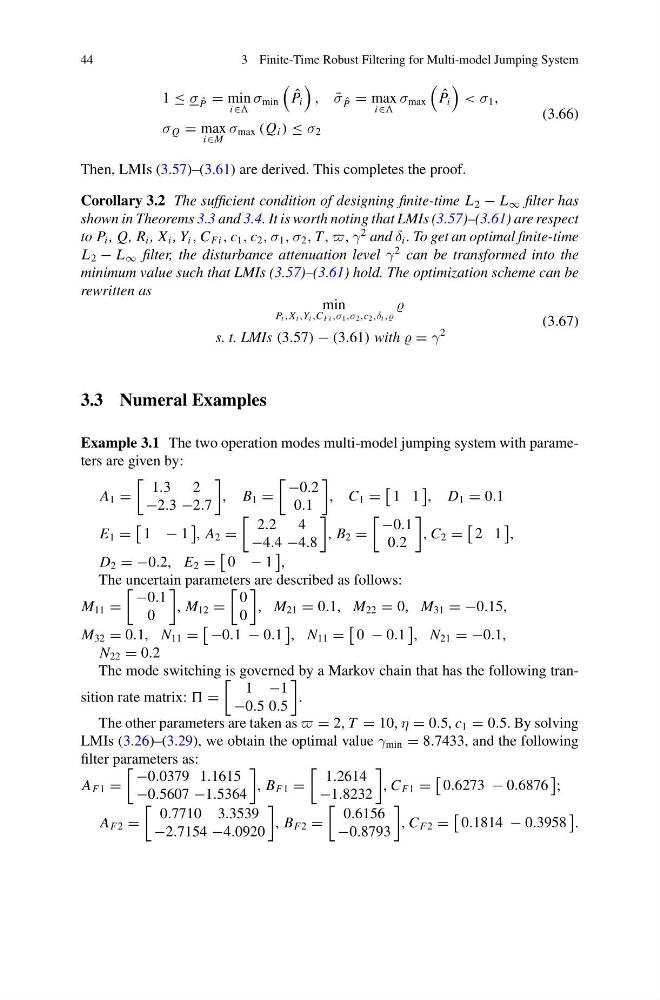
Then, LMIs (3.57)–(3.61) are derived. This completes the proof.
Corollary 3.2 The sufficient condition of designing finite-time L 2 − L ∞ filter has
shown in Theorems 3.3 and 3.4. It is worth noting that LMIs (3.57)–(3.61) are respect
to P i , Q, R i , X i , Y i , C Fi , c 1 , c 2 , σ 1 , σ 2 , T, , γ
2 and δ i . To get an optimal finite-time
L 2 − L ∞ filter, the disturbance attenuation level γ
2 can be transformed into the
minimum value such that LMIs (3.57)–(3.61) hold. The optimization scheme can be
rewritten as
min
P i ,X i ,Y i ,C Fi ,σ 1 ,σ 2 ,c 2 ,δ i ,
s. t. LMIs (3.57) − (3.61) with = γ
2
(3.67)
3.3 Numeral Examples
Example 3.1 The two operation modes multi-model jumping system with parameters are given by:
A 1 =
1.3 2
−2.3 −2.7
, B 1 =
−0.2
0.1
, C 1 =
1 1
, D 1 = 0.1
E 1 =
1 − 1
, A 2 =
2.2 4
−4.4 −4.8
, B 2 =
−0.1
0.2
, C 2 =
2 1
,
D 2 = −0.2, E 2 =
0 − 1
,
The uncertain parameters are described as follows:
M 11 =
−0.1
0
, M 12 =
0
0
, M 21 = 0.1, M 22 = 0, M 31 = −0.15,
M 32 = 0.1, N 11 =
−0.1 − 0.1
, N 11 =
0 − 0.1
, N 21 = −0.1,
N 22 = 0.2
The mode switching is governed by a Markov chain that has the following transition rate matrix: =
1 −1
−0.5 0.5
.
The other parameters are taken as = 2, T = 10, η = 0.5, c 1 = 0.5. By solving
LMIs (3.26)–(3.29), we obtain the optimal value γ min = 8.7433, and the following
filter parameters as:
A F1 =
−0.0379 1.1615
−0.5607 −1.5364
, B F1 =
1.2614
−1.8232
, C F1 =
0.6273 − 0.6876
;
A F2 =
0.7710 3.3539
−2.7154 −4.0920
, B F2 =
0.6156
−0.8793
, C F2 =
0.1814 − 0.3958
.