

3.1 Finite-Time Robust H ∞ Filtering for Multi-model Jumping System
35
Then one obtains
E
˜
x
T
(t) ˜
R i ˜
x(t)
<
e
ηT
[c 1 ( ¯
σ ˆ
P + τ σ Q i ) + ( ¯
γ
2
/η)(1 − e
−ηT
)]
σ ˆ
P
(3.25)
Therefore, E
˜
x
T
(t) ˜
R i ˜
x(t)
< c 2 can be derived for ∀t ∈ [0 T ]. This completes the
proof.
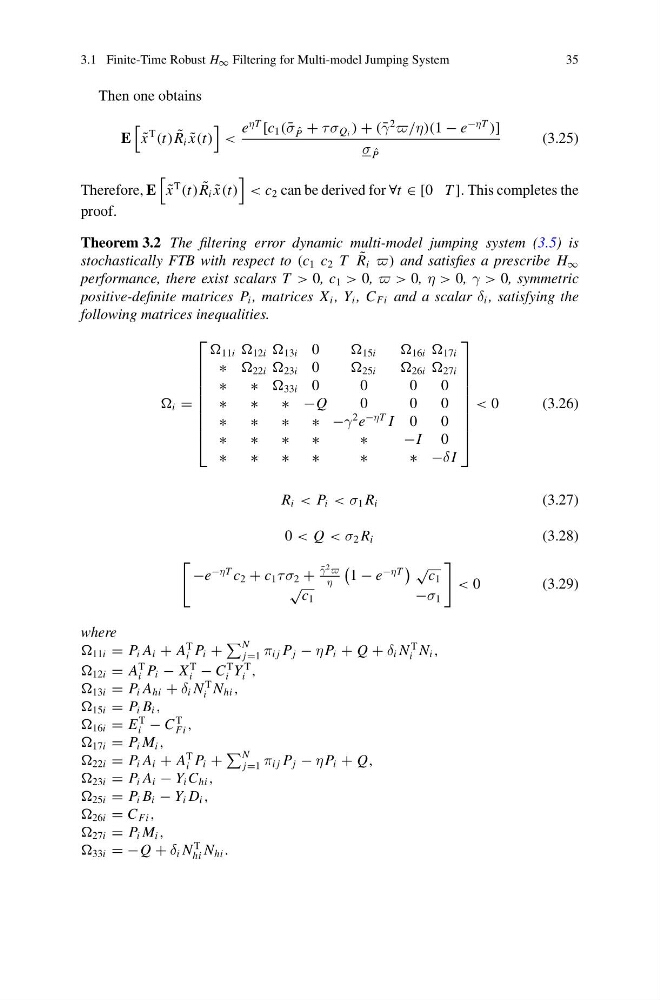
Theorem 3.2 The filtering error dynamic multi-model jumping system (3.5) is
stochastically FTB with respect to (c 1 c 2 T ˜
R i ) and satisfies a prescribe H ∞
performance, there exist scalars T > 0, c 1 > 0, > 0, η > 0, γ > 0, symmetric
positive-definite matrices P i , matrices X i , Y i , C Fi and a scalar δ i , satisfying the
following matrices inequalities.
i =
⎡
⎢
⎢
⎢
⎢
⎢
⎢
⎢
⎢
⎣
11i 12i 13i 0
15i
16i 17i
∗ 22i 23i 0
25i
26i 27i
∗
∗ 33i 0
0
0
0
∗
∗
∗ −Q
0
0
0
∗
∗
∗ ∗ −γ
2 e
−ηT I 0
0
∗
∗
∗ ∗
∗
−I 0
∗
∗
∗ ∗
∗
∗ −δ I
⎤
⎥
⎥
⎥
⎥
⎥
⎥
⎥
⎥
⎦
< 0
(3.26)
R i < P i < σ 1 R i
(3.27)
0 < Q < σ 2 R i
(3.28)
−e
−ηT c 2 + c 1 τ σ 2 +
¯
γ
2
η
1 − e
−ηT
√ c 1
√ c 1
−σ 1
< 0
(3.29)
where
11i = P i A i + A
T
i P i +
N
j=1 π i j P j − η P i + Q + δ i N
T
i N i ,
12i = A
T
i P i − X
T
i − C
T
i Y
T
i ,
13i = P i A hi + δ i N
T
i N hi ,
15i = P i B i ,
16i = E
T
i − C
T
Fi ,
17i = P i M i ,
22i = P i A i + A
T
i P i +
N
j=1 π i j P j − η P i + Q,
23i = P i A i − Y i C hi ,
25i = P i B i − Y i D i ,
26i = C Fi ,
27i = P i M i ,
33i = −Q + δ i N
T
hi N hi .