

170
9 Neural Network-Based Robust Fault Detection …
0
5
10
15
20
0
1
2
3
4
5
6
7
8
9
t/s
The evaluation function J(r,t)
fault case
fault−free case
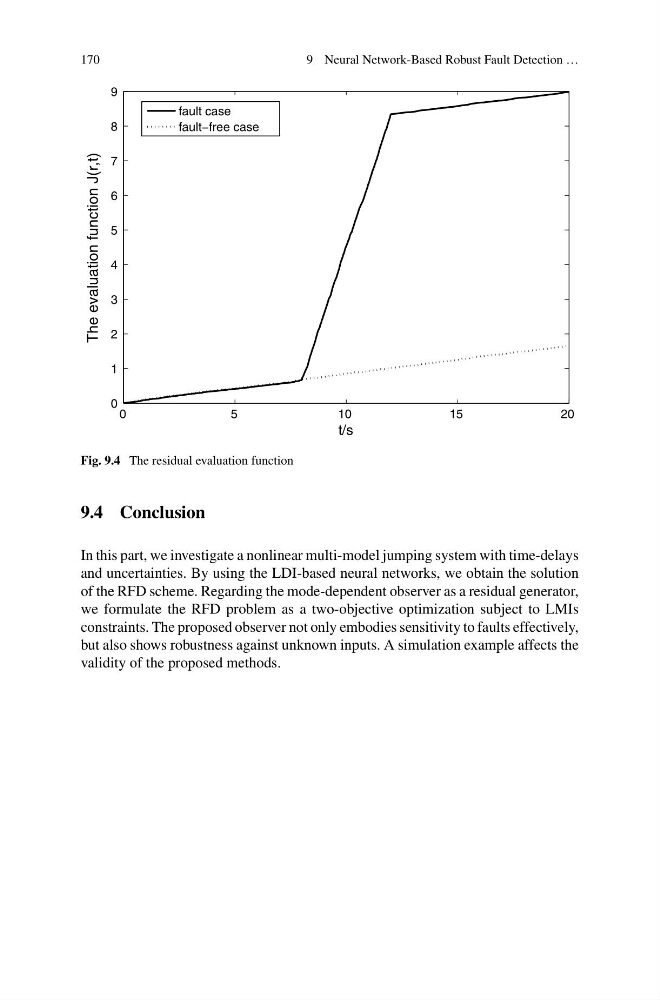
Fig. 9.4 The residual evaluation function
9.4 Conclusion
In this part, we investigate a nonlinear multi-model jumping system with time-delays
and uncertainties. By using the LDI-based neural networks, we obtain the solution
of the RFD scheme. Regarding the mode-dependent observer as a residual generator,
we formulate the RFD problem as a two-objective optimization subject to LMIs
constraints. The proposed observer not only embodies sensitivity to faults effectively,
but also shows robustness against unknown inputs. A simulation example affects the
validity of the proposed methods.