

166
9 Neural Network-Based Robust Fault Detection …
P 1i B f i + δ i N
T
f i N 4i
P 1i M i
P 1i
P 2i B f i − ¯
H i D f i − C
T
i
P 2i M i − ¯
H i M yi 0
−C
T
hi + δ i N
T
hi N f i
0
0
2η I − D
T
f i − D f i + δ i N
T
f i N f i
−M yi
0
∗
− δ i I
0
∗
∗
− β i I
⎤
⎥
⎥
⎥
⎥
⎥
⎥
⎦
< 0, (9.24)
where
11 = P 1i A
i +
A
i
T P 1i +
N
j=1 π i j P 1 j + Q + δ i N
T
i N i + β i ρ
2
i I.
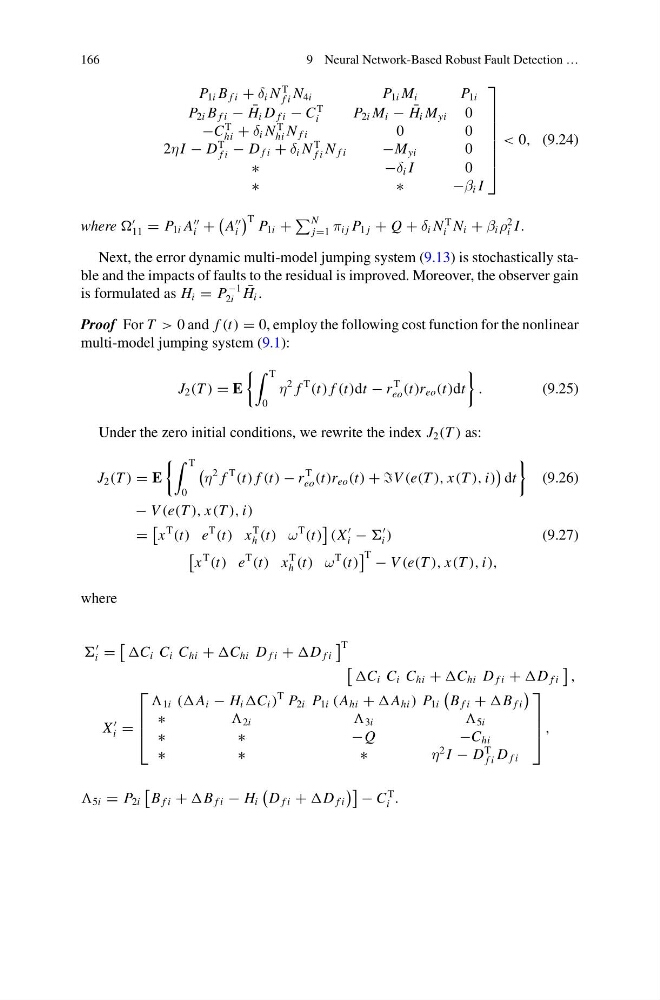
Next, the error dynamic multi-model jumping system (9.13) is stochastically stable and the impacts of faults to the residual is improved. Moreover, the observer gain
is formulated as H i = P
−1
2i
¯
H i .
Proof For T > 0 and f (t) = 0, employ the following cost function for the nonlinear
multi-model jumping system (9.1):
J 2 (T ) = E
T
0
η
2 f
T
(t) f (t)dt − r
T
eo (t)r eo (t)dt
.
(9.25)
Under the zero initial conditions, we rewrite the index J 2 (T ) as:
J 2 (T ) = E
T
0
η
2 f
T
(t) f (t) − r
T
eo (t)r eo (t) + +V (e(T ), x(T ), i)
dt
(9.26)
− V (e(T ), x(T ), i)
=
x
T
(t) e
T
(t) x
T
h (t) ω
T
(t)
(X
i −
i )
(9.27)
x
T
(t) e
T
(t) x
T
h (t) ω
T
(t)
T − V (e(T ), x(T ), i),
where
i =
C i C i C hi + C hi D f i + D f i
T
C i C i C hi + C hi D f i + D f i
,
X
i =
⎡
⎢
⎢
⎣
1i (A i − H i C i )
T P 2i P 1i (A hi + A hi ) P 1i
B f i + B f i
∗
2i
3i
5i
∗
∗
− Q
−C hi
∗
∗
∗
η
2 I − D
T
f i D f i
⎤
⎥
⎥
⎦ ,
5i = P 2i
B f i + B f i − H i
D f i + D f i
− C
T
i .