

8.2 FDF Design for Fuzzy Multi-model Jumping System
157
0
5
10
15
−1
−0.5
0
0.5
1
1.5
t/s
The residual signal r(t)
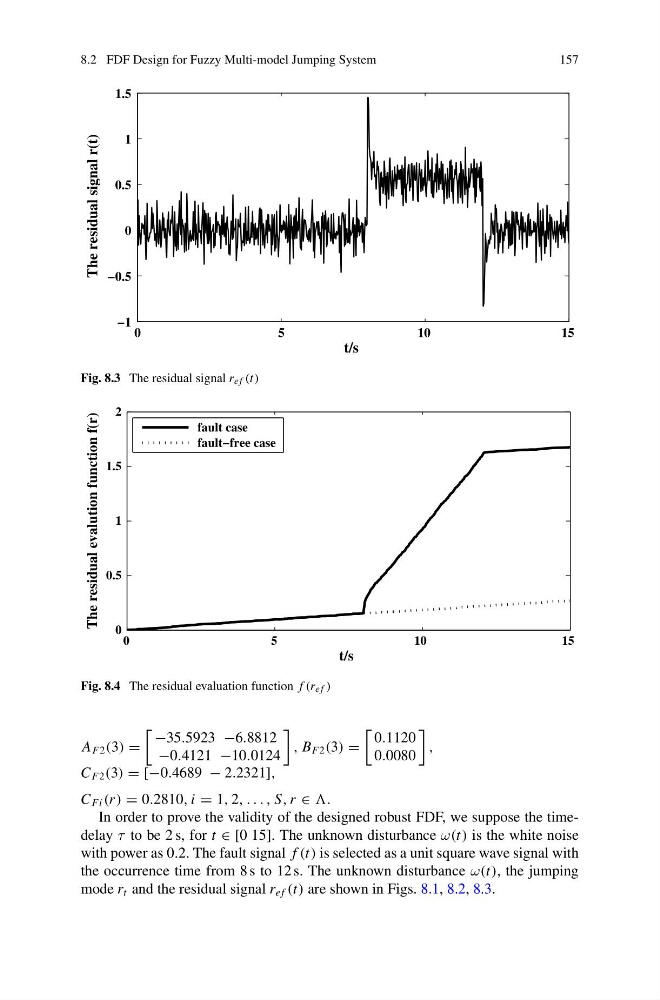
Fig. 8.3 The residual signal r e f (t)
0
5
10
15
0
0.5
1
1.5
2
t/s
The residual evalution function f(r)
fault case
fault−free case
Fig. 8.4 The residual evaluation function f (r ef )
A F2 (3) =
−35.5923 −6.8812
−0.4121 −10.0124
, B F2 (3) =
0.1120
0.0080
,
C F2 (3) = [−0.4689 − 2.2321],
C Fi (r ) = 0.2810, i = 1, 2, . . . , S, r ∈ .
In order to prove the validity of the designed robust FDF, we suppose the timedelay τ to be 2 s, for t ∈ [0 15]. The unknown disturbance ω(t) is the white noise
with power as 0.2. The fault signal f (t) is selected as a unit square wave signal with
the occurrence time from 8 s to 12 s. The unknown disturbance ω(t), the jumping
mode r t and the residual signal r e f (t) are shown in Figs. 8.1, 8.2, 8.3.