

7.1 Robust FDO Design for Fuzzy Multi-model Jumping System
121
7.1.2 Design of Robust FDO for Fuzzy Multi-model Jumping
System
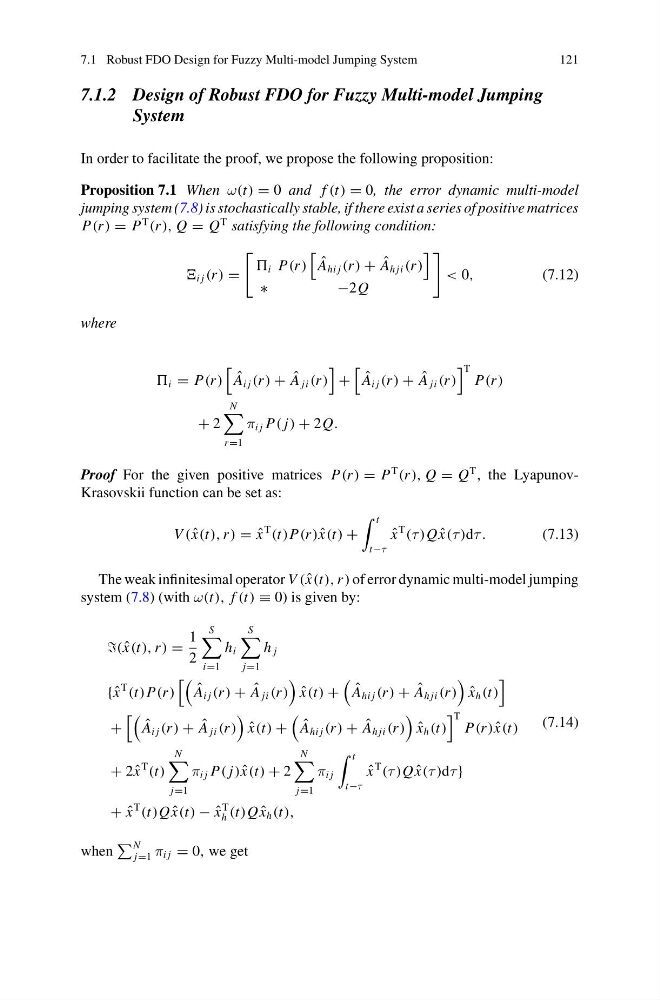
In order to facilitate the proof, we propose the following proposition:
Proposition 7.1 When ω(t) = 0 and f (t) = 0, the error dynamic multi-model
jumping system (7.8) is stochastically stable, if there exist a series of positive matrices
P(r ) = P
T
(r ), Q = Q
T satisfying the following condition:
i j (r ) =
i P(r )
ˆ
A hi j (r ) + ˆ
A h ji (r )
∗
− 2Q
< 0,
(7.12)
where
i = P(r )
ˆ
A i j (r ) + ˆ
A ji (r )
+
ˆ
A i j (r ) + ˆ
A ji (r )
T
P(r )
+ 2
N
r =1
π i j P( j) + 2Q.
Proof For the given positive matrices P(r ) = P
T
(r ), Q = Q
T , the LyapunovKrasovskii function can be set as:
V ( ˆ
x(t), r ) = ˆ
x
T
(t)P(r ) ˆ
x(t) +
t
t−τ
ˆ
x
T
(τ )Q ˆ
x(τ )dτ .
(7.13)
The weak infinitesimal operator V ( ˆ
x(t), r ) of error dynamic multi-model jumping
system (7.8) (with ω(t), f (t) ≡ 0) is given by:
( ˆ
x(t), r ) =
1
2
S
i=1
h i
S
j=1
h j
{ ˆ
x
T
(t)P(r )
ˆ
A i j (r ) + ˆ
A ji (r )
ˆ
x(t) +
ˆ
A hi j (r ) + ˆ
A h ji (r )
ˆ
x h (t)
+
ˆ
A i j (r ) + ˆ
A ji (r )
ˆ
x(t) +
ˆ
A hi j (r ) + ˆ
A h ji (r )
ˆ
x h (t)
T
P(r ) ˆ
x(t)
+ 2 ˆ
x
T
(t)
N
j=1
π i j P( j) ˆ
x(t) + 2
N
j=1
π i j
t
t−τ
ˆ
x
T
(τ )Q ˆ
x(τ )dτ }
+ ˆ
x
T
(t)Q ˆ
x(t) − ˆ
x
T
h (t)Q ˆ
x h (t),
(7.14)
when
N
j=1 π i j = 0, we get