

118
7 Observer-Based Robust Fault Detection for Fuzzy Multi-model Jumping System
7.1 Robust FDO Design for Fuzzy Multi-model Jumping
System
7.1.1 System Description
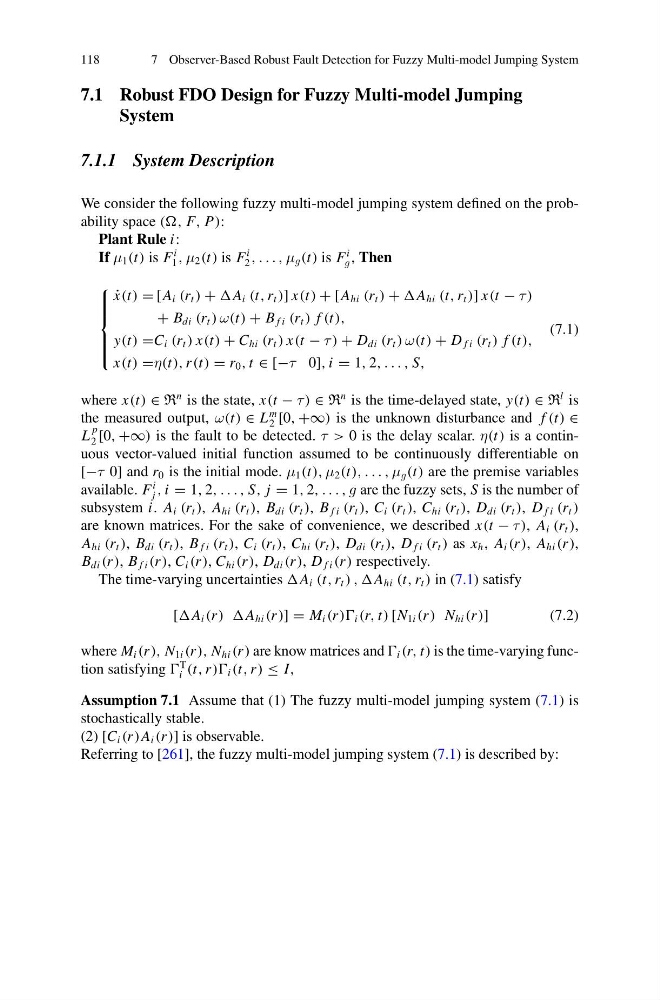
We consider the following fuzzy multi-model jumping system defined on the probability space ((, F, P):
Plant Rule i:
If μ 1 (t) is F
i
1 , μ 2 (t) is F
i
2 , . . . , μ g (t) is F
i
g , Then
⎧
⎪ ⎪ ⎪ ⎨
⎪ ⎪ ⎪ ⎩
˙
x(t) = [A i (r t ) + A i (t, r t )] x(t) + [A hi (r t ) + A hi (t, r t )] x(t − τ )
+ B di (r t ) ω(t) + B f i (r t ) f (t),
y(t) =C i (r t ) x(t) + C hi (r t ) x(t − τ ) + D di (r t ) ω(t) + D f i (r t ) f (t),
x(t) =η(t), r (t) = r 0 , t ∈ [−τ 0], i = 1, 2, . . . , S,
(7.1)
where x(t) ∈ R
n is the state, x(t − τ ) ∈ R
n is the time-delayed state, y(t) ∈ R
l is
the measured output, ω(t) ∈ L
m
2 [0, +∞) is the unknown disturbance and f (t) ∈
L
p
2 [0, +∞) is the fault to be detected. τ > 0 is the delay scalar. η(t) is a continuous vector-valued initial function assumed to be continuously differentiable on
[−τ 0] and r 0 is the initial mode. μ 1 (t), μ 2 (t), . . . , μ g (t) are the premise variables
available. F
i
j , i = 1, 2, . . . , S, j = 1, 2, . . . , g are the fuzzy sets, S is the number of
subsystem i. A i (r t ), A hi (r t ), B di (r t ), B f i (r t ), C i (r t ), C hi (r t ), D di (r t ), D f i (r t )
are known matrices. For the sake of convenience, we described x(t − τ ), A i (r t ),
A hi (r t ), B di (r t ), B f i (r t ), C i (r t ), C hi (r t ), D di (r t ), D f i (r t ) as x h , A i (r ), A hi (r ),
B di (r ), B f i (r ), C i (r ), C hi (r ), D di (r ), D f i (r ) respectively.
The time-varying uncertainties A i (t, r t ) , ,A hi (t, r t ) in (7.1) satisfy
[A i (r ) )A hi (r )] = M i (r )) i (r, t) [N 1i (r ) N hi (r )]
(7.2)
where M i (r ), N 1i (r ), N hi (r ) are know matrices and i (r, t) is the time-varying function satisfying
T
i (t, r )) i (t, r ) ≤ I,
Assumption 7.1 Assume that (1) The fuzzy multi-model jumping system (7.1) is
stochastically stable.
(2) [C i (r )A i (r )] is observable.
Referring to [261], the fuzzy multi-model jumping system (7.1) is described by: