

6.3 Numeral Examples
109
A 1 =
−0.2 5
−0.8 −5
, A 2 =
−5.2 8
−0.5 −6
, A 3 =
−8.8 3
−1.2 −4
,
B di =
0
0.1
, C i =
1 0
, D di = 0.1, M i =
0 0
, N i = [0 0].
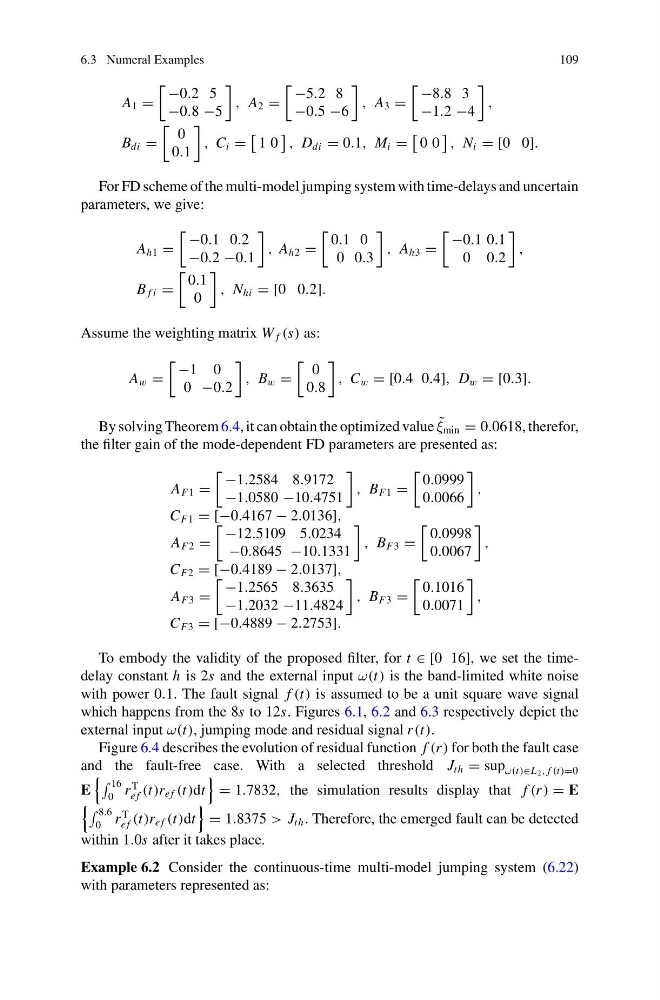
For FD scheme of the multi-model jumping system with time-delays and uncertain
parameters, we give:
A h1 =
−0.1 0.2
−0.2 −0.1
, A h2 =
0.1 0
0 0.3
, A h3 =
−0.1 0.1
0 0.2
,
B f i =
0.1
0
, N hi = [0 0.2].
Assume the weighting matrix W f (s) as:
A w =
−1 0
0 −0.2
, B w =
0
0.8
, C w = [0.4 0.4], D w = [0.3].
By solving Theorem 6.4, it can obtain the optimized value ˜
ξ min = 0.0618, therefor,
the filter gain of the mode-dependent FD parameters are presented as:
A F1 =
−1.2584 8.9172
−1.0580 −10.4751
, B F1 =
0.0999
0.0066
,
C F1 = [−0.4167 − 2.0136],
A F2 =
−12.5109 5.0234
−0.8645 −10.1331
, B F3 =
0.0998
0.0067
,
C F2 = [−0.4189 − 2.0137],
A F3 =
−1.2565 8.3635
−1.2032 −11.4824
, B F3 =
0.1016
0.0071
,
C F3 = [−0.4889 − 2.2753].
To embody the validity of the proposed filter, for t ∈ [0 16], we set the timedelay constant h is 2s and the external input ω(t) is the band-limited white noise
with power 0.1. The fault signal f (t) is assumed to be a unit square wave signal
which happens from the 8s to 12s. Figures 6.1, 6.2 and 6.3 respectively depict the
external input ω(t), jumping mode and residual signal r (t).
Figure 6.4 describes the evolution of residual function f (r ) for both the fault case
and the fault-free case. With a selected threshold J th = sup ω(t)∈L 2 , f (t)=0
E
16
0 r
T
e f (t)r e f (t)dt
= 1.7832, the simulation results display that f (r ) = E
8.6
0 r
T
e f (t)r e f (t)dt
= 1.8375 > J th . Therefore, the emerged fault can be detected
within 1.0s after it takes place.
Example 6.2 Consider the continuous-time multi-model jumping system (6.22)
with parameters represented as: