

106
6 Robust Fault Detection for Multi-model Jumping System
1 = [
√
π i1 · · ·
√ π ii−1 ,
√ π ii+1 · · ·
√ π i j ],
2 = −diag{P 1 · · · P i−1 , P i+1 · · · P i j }.
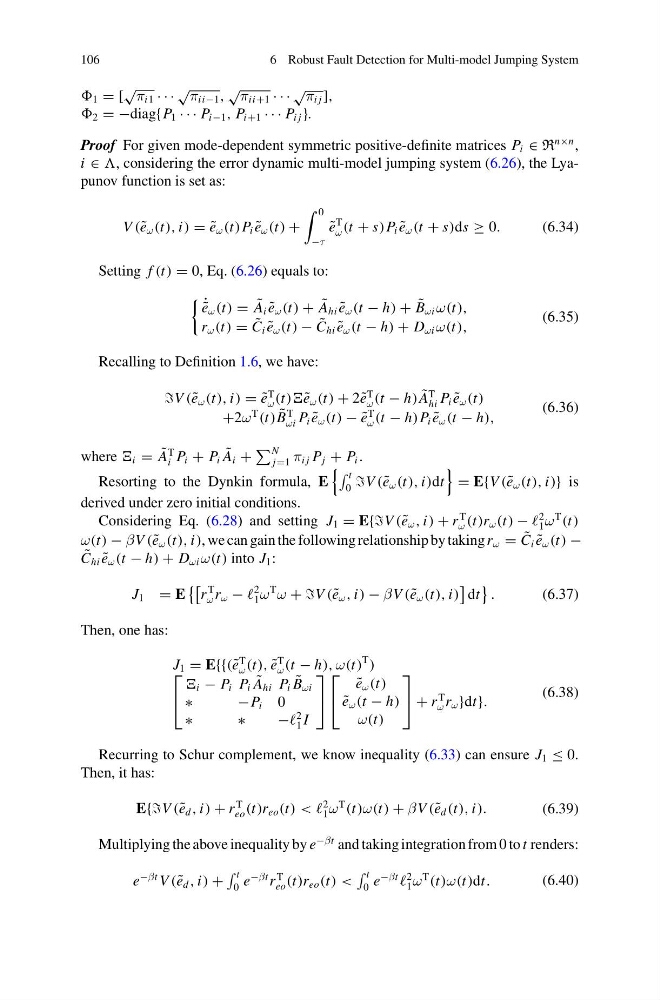
Proof For given mode-dependent symmetric positive-definite matrices P i ∈ R
n×n ,
i ∈ , considering the error dynamic multi-model jumping system (6.26), the Lyapunov function is set as:
V ( ˜
e ω (t), i) = ˜
e ω (t)P i ˜
e ω (t) +
0
−τ
˜
e
T
ω (t + s)P i ˜
e ω (t + s)ds ≥ 0.
(6.34)
Setting f (t) = 0, Eq. (6.26) equals to:
˙ ˜
e ω (t) = ˜
A i ˜
e ω (t) + ˜
A hi ˜
e ω (t − h) + ˜
B ωi ω(t),
r ω (t) = ˜
C i ˜
e ω (t) − ˜
C hi ˜
e ω (t − h) + D ωi ω(t),
(6.35)
Recalling to Definition 1.6, we have:
V ( ˜
e ω (t), i) = ˜
e
T
ω (t)) ˜
e ω (t) + 2 ˜
e
T
ω (t − h) ˜
A
T
hi P i ˜
e ω (t)
+2ω
T
(t) ˜
B
T
ωi P i ˜
e ω (t) − ˜
e
T
ω (t − h)P i ˜
e ω (t − h),
(6.36)
where i = ˜
A
T
i P i + P i ˜
A i +
N
j=1 π i j P j + P i .
Resorting to the Dynkin formula, E
t
0 V ( ˜
e ω (t), i)dt
= E{V ( ˜
e ω (t), i)} is
derived under zero initial conditions.
Considering Eq. (6.28) and setting J 1 = E{{V ( ˜
e ω , i) + r
T
ω (t)r ω (t) −
2
1 ω
T
(t)
ω(t) − βV ( ˜
e ω (t), i), we can gain the following relationship by taking r ω = ˜
C i ˜
e ω (t) −
˜
C hi ˜
e ω (t − h) + D ωi ω(t) into J 1 :
J 1 = E
r
T
ω r ω −
2
1 ω
T
ω + +V ( ˜
e ω , i) − βV ( ˜
e ω (t), i)
dt
.
(6.37)
Then, one has:
J 1 = E{{( ˜
e
T
ω (t), ˜
e
T
ω (t − h), ω(t)
T
)
⎡
⎣
i − P i P i ˜
A hi P i ˜
B ωi
∗
−P i 0
∗
∗
−
2
1 I
⎤
⎦
⎡
⎣
˜
e ω (t)
˜
e ω (t − h)
ω(t)
⎤
⎦ + r
T
ω r ω }dt}.
(6.38)
Recurring to Schur complement, we know inequality (6.33) can ensure J 1 ≤ 0.
Then, it has:
E{{V ( ˜
e d , i) + r
T
eo (t)r eo (t) < <
2
1 ω
T
(t)ω(t) + βV ( ˜
e d (t), i).
(6.39)
Multiplying the above inequality by e
−βt and taking integration from 0 to t renders:
e
−βt V ( ˜
e d , i) +
t
0 e
−βt r
T
eo (t)r eo (t) <
t
0 e
−βt
2
1 ω
T
(t)ω(t)dt.
(6.40)