

6.2 Robust FD Observer Design for Multi-model Jumping System
105
observer which can reflect the restriction of disturbances on residual and sensitivity
of the faults to residual, the obtained matrix H i should satisfy inequality (6.28) and
inequality (6.29), simultaneously. Accordingly, to accomplish the optimal balance
between the robustness against disturbances and the sensitivity to faults, the FD
observer for the continuous-time multi-model jumping system (6.22) is expressed
to get H i such that, under zero initial conditions, the error dynamic multi-model
jumping system (6.26) is stochastically stable and yields:
J e = γ 1 /γ 2 .
(6.32)
6.2.2 Observer Analysis and Design of Multi-model Jumping
System
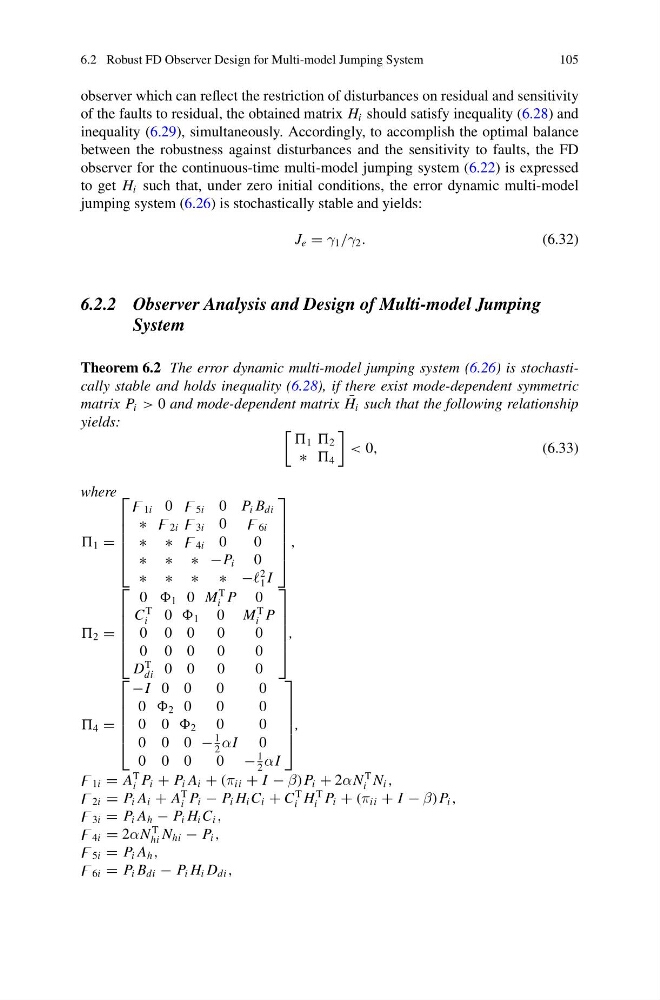
Theorem 6.2 The error dynamic multi-model jumping system (6.26) is stochastically stable and holds inequality (6.28), if there exist mode-dependent symmetric
matrix P i > 0 and mode-dependent matrix ¯
H i such that the following relationship
yields:
1 2
∗ 4
< 0,
(6.33)
where
1 =
⎡
⎢
⎢
⎢
⎢
⎣
1i 0 5i 0 P i B di
∗ 2i 3i 0 6i
∗ ∗ 4i 0
0
∗ ∗ ∗ −P i 0
∗ ∗ ∗ ∗ −
2
1 I
⎤
⎥
⎥
⎥
⎥
⎦
,
2 =
⎡
⎢
⎢
⎢
⎢
⎣
0 1 0 M
T
i P 0
C
T
i
0 1 0 M
T
i P
0 0 0
0
0
0 0 0
0
0
D
T
di 0 0
0
0
⎤
⎥
⎥
⎥
⎥
⎦
,
4 =
⎡
⎢
⎢
⎢
⎢
⎣
−I 0 0
0
0
0 2 0
0
0
0 0 2 0
0
0 0 0 −
1
2
αI 0
0 0 0
0 −
1
2
αI
⎤
⎥
⎥
⎥
⎥
⎦
,
1i = A
T
i P i + P i A i + (π ii + I − β)P i + 2αN
T
i N i ,
2i = P i A i + A
T
i P i − P i H i C i + C
T
i H
T
i P i + (π ii + I − β)P i ,
3i = P i A h − P i H i C i ,
4i = 2αN
T
hi N hi − P i ,
5i = P i A h ,
6i = P i B di − P i H i D di ,