

6.2 Robust FD Observer Design for Multi-model Jumping System
103
where M i , N i , N hi are constant matrices with appropriate dimensions and i (t)
is the unknown time-varying matrix with Lebesgue measurable elements holding
T
i (t)) i (t) ≤ I .
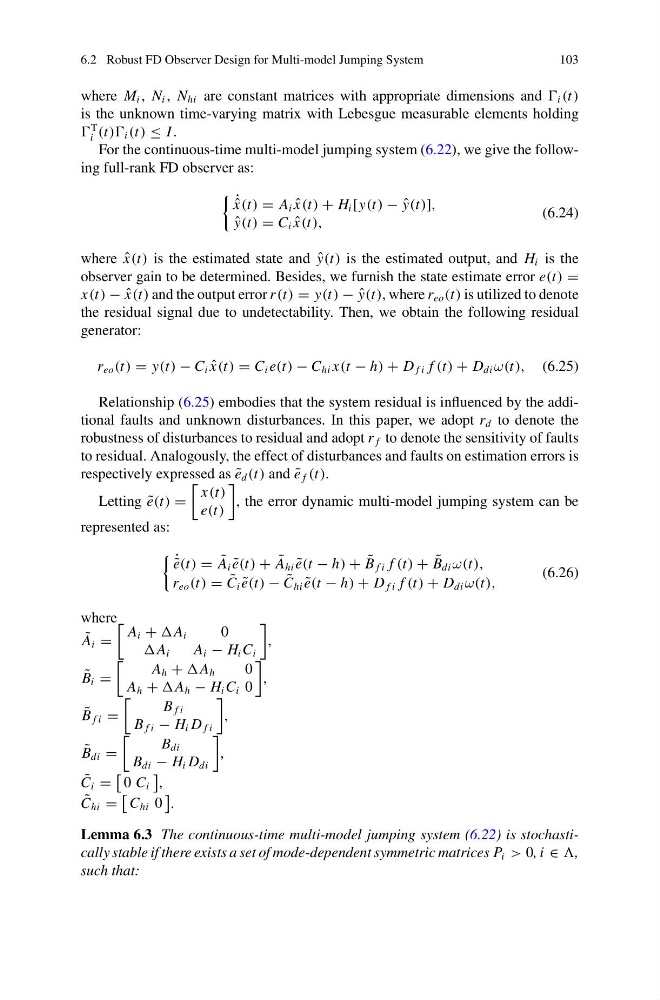
For the continuous-time multi-model jumping system (6.22), we give the following full-rank FD observer as:
˙ ˆ
x(t) = A i ˆ
x(t) + H i [y(t) − ˆ
y(t)],
ˆ
y(t) = C i ˆ
x(t),
(6.24)
where ˆ
x(t) is the estimated state and ˆ
y(t) is the estimated output, and H i is the
observer gain to be determined. Besides, we furnish the state estimate error e(t) =
x(t) − ˆ
x(t) and the output error r (t) = y(t) − ˆ
y(t), where r eo (t) is utilized to denote
the residual signal due to undetectability. Then, we obtain the following residual
generator:
r eo (t) = y(t) − C i ˆ
x(t) = C i e(t) − C hi x(t − h) + D f i f (t) + D di ω(t), (6.25)
Relationship (6.25) embodies that the system residual is influenced by the additional faults and unknown disturbances. In this paper, we adopt r d to denote the
robustness of disturbances to residual and adopt r f to denote the sensitivity of faults
to residual. Analogously, the effect of disturbances and faults on estimation errors is
respectively expressed as ˜
e d (t) and ˜
e f (t).
Letting ˜
e(t) =
x(t)
e(t)
, the error dynamic multi-model jumping system can be
represented as:
˙ ˜
e(t) = ˜
A i ˜
e(t) + ˜
A hi ˜
e(t − h) + ˜
B f i f (t) + ˜
B di ω(t),
r eo (t) = ˜
C i ˜
e(t) − ˜
C hi ˜
e(t − h) + D f i f (t) + D di ω(t),
(6.26)
where
˜
A i =
A i + A i
0
A i
A i − H i C i
,
˜
B i =
A h + A h
0
A h + A h − H i C i 0
,
˜
B f i =
B f i
B f i − H i D f i
,
˜
B di =
B di
B di − H i D di
,
˜
C i =
0 C i
,
˜
C hi =
C hi 0
.
Lemma 6.3 The continuous-time multi-model jumping system (6.22) is stochastically stable if there exists a set of mode-dependent symmetric matrices P i > 0, i ∈ ,
such that: