

5.5 Computational Note: Methods for Nonadiabatic Dynamics
171
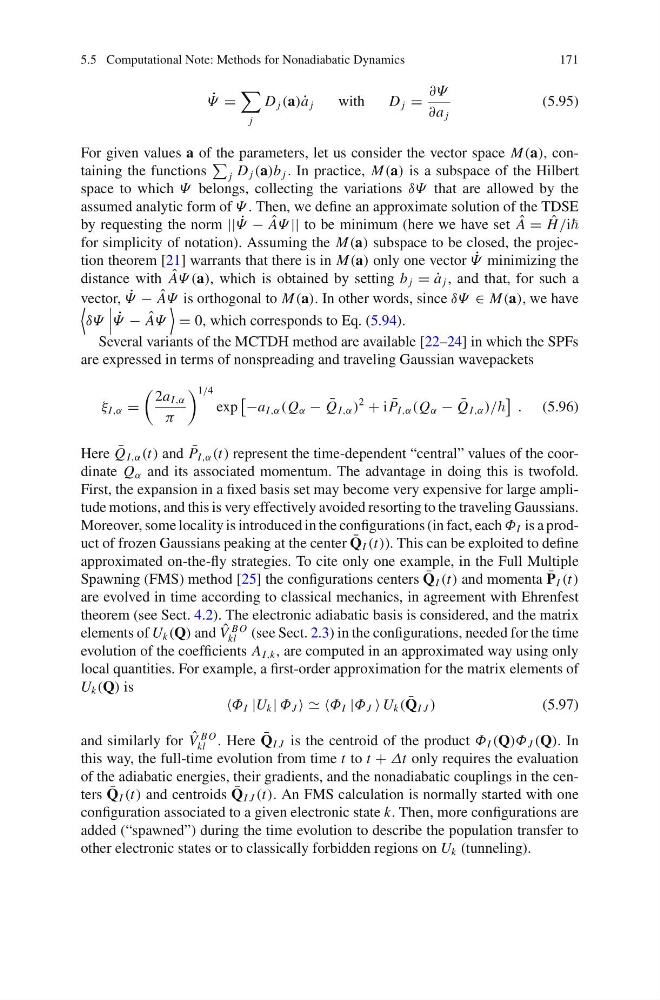
˙
Ψ =
j
D j (a) ˙
a j
with
D j =
∂Ψ
∂a j
(5.95)
For given values a of the parameters, let us consider the vector space M(a), containing the functions
j D j (a)b j . In practice, M(a) is a subspace of the Hilbert
space to which Ψ belongs, collecting the variations δΨ that are allowed by the
assumed analytic form of Ψ . Then, we define an approximate solution of the TDSE
by requesting the norm || ˙
Ψ − ˆ
AΨ || to be minimum (here we have set ˆ
A = ˆ
H /i
for simplicity of notation). Assuming the M(a) subspace to be closed, the projection theorem [21] warrants that there is in M(a) only one vector ˙
Ψ minimizing the
distance with ˆ
AΨ (a), which is obtained by setting b j = ˙
a j , and that, for such a
vector, ˙
Ψ − ˆ
AΨ is orthogonal to M(a). In other words, since δΨ ∈ M(a), we have
δΨ
˙
Ψ − ˆ
AΨ
= 0, which corresponds to Eq. (5.94).
Several variants of the MCTDH method are available [22–24] in which the SPFs
are expressed in terms of nonspreading and traveling Gaussian wavepackets
ξ I,α =
2a I,α
π
1/4
exp
−a I,α (Q α − ¯
Q I,α )
2
+ i ¯
P I,α (Q α − ¯
Q I,α )/
. (5.96)
Here ¯
Q I,α (t) and ¯
P I,α (t) represent the time-dependent “central” values of the coordinate Q α and its associated momentum. The advantage in doing this is twofold.
First, the expansion in a fixed basis set may become very expensive for large amplitude motions, and this is very effectively avoided resorting to the traveling Gaussians.
Moreover, some locality is introduced in the configurations (in fact, each Φ I is a product of frozen Gaussians peaking at the center ¯
Q I (t)). This can be exploited to define
approximated on-the-fly strategies. To cite only one example, in the Full Multiple
Spawning (FMS) method [25] the configurations centers ¯
Q I (t) and momenta ¯
P I (t)
are evolved in time according to classical mechanics, in agreement with Ehrenfest
theorem (see Sect. 4.2). The electronic adiabatic basis is considered, and the matrix
elements of U k (Q) and ˆ
V
B O
kl (see Sect. 2.3) in the configurations, needed for the time
evolution of the coefficients A I,k , are computed in an approximated way using only
local quantities. For example, a first-order approximation for the matrix elements of
U k (Q) is
Φ I |U k | Φ J Φ I |Φ J U k ( ¯
Q I J )
(5.97)
and similarly for ˆ
V
B O
kl . Here ¯
Q I J is the centroid of the product Φ I (Q)Φ J (Q). In
this way, the full-time evolution from time t to t + Δt only requires the evaluation
of the adiabatic energies, their gradients, and the nonadiabatic couplings in the centers ¯
Q I (t) and centroids ¯
Q I J (t). An FMS calculation is normally started with one
configuration associated to a given electronic state k. Then, more configurations are
added (“spawned”) during the time evolution to describe the population transfer to
other electronic states or to classically forbidden regions on U k (tunneling).