

26 Beam-based Correction and Optimization for Accelerators
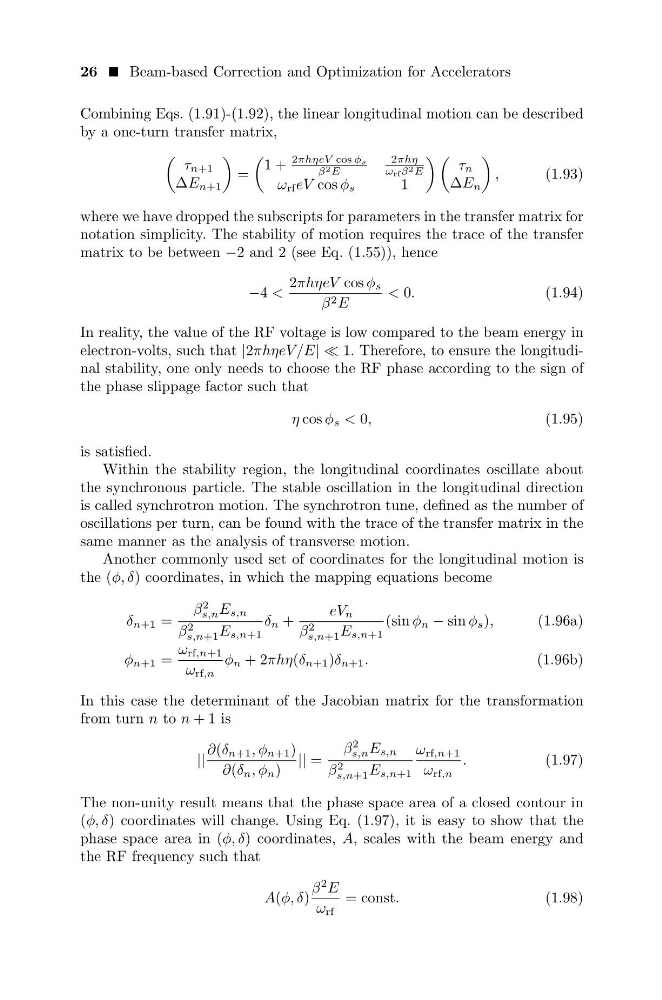
Combining Eqs. (1.91)-(1.92), the linear longitudinal motion can be described
by a one-turn transfer matrix,
τ n+1
∆E n+1
=
1 +
2πhηeV cos φs
β 2 E
2πhη
ω rf β 2 E
ω rf eV cos φ s
1
τ n
∆E n
,
(1.93)
where we have dropped the subscripts for parameters in the transfer matrix for
notation simplicity. The stability of motion requires the trace of the transfer
matrix to be between −2 and 2 (see Eq. (1.55)), hence
−4 <
2πhηeV cos φ s
β 2 E
< 0.
(1.94)
In reality, the value of the RF voltage is low compared to the beam energy in
electron-volts, such that |2πhηeV /E| | 1. Therefore, to ensure the longitudinal stability, one only needs to choose the RF phase according to the sign of
the phase slippage factor such that
η cos φ s < 0,
(1.95)
is satisfied.
Within the stability region, the longitudinal coordinates oscillate about
the synchronous particle. The stable oscillation in the longitudinal direction
is called synchrotron motion. The synchrotron tune, defined as the number of
oscillations per turn, can be found with the trace of the transfer matrix in the
same manner as the analysis of transverse motion.
Another commonly used set of coordinates for the longitudinal motion is
the (φ, δ) coordinates, in which the mapping equations become
δ n+1 =
β
2
s,n E s,n
β 2
s,n+1 E s,n+1
δ n +
eV n
β 2
s,n+1 E s,n+1
(sin φ n − sin φ s ),
(1.96a)
φ n+1 =
ω rf,n+1
ω rf,n
φ n + 2πhη(δ n+1 )δ n+1 .
(1.96b)
In this case the determinant of the Jacobian matrix for the transformation
from turn n to n + 1 is
||
∂(δ n+1 , φ n+1 )
∂(δ n , φ n )
|| =
β
2
s,n E s,n
β 2
s,n+1 E s,n+1
ω rf,n+1
ω rf,n
.
(1.97)
The non-unity result means that the phase space area of a closed contour in
(φ, δ) coordinates will change. Using Eq. (1.97), it is easy to show that the
phase space area in (φ, δ) coordinates, A, scales with the beam energy and
the RF frequency such that
A(φ, δ)
β
2 E
ω rf
= const.
(1.98)