

10 Beam-based Correction and Optimization for Accelerators
Drift space: In a drift space, h = 0 and B x = B y = 0. The equations of
motion in the transverse directions are reduced to
x
= 0,
y
= 0.
(1.24)
The solution is given by the initial conditions,
x(s) = x 0 + x
0 s,
x
(s) = x
0 ,
(1.25a)
y(s) = y 0 + y
0 s,
y
(s) = y
0 ,
(1.25b)
where subscript 0 indicates values at the entrance face. The phase space coordinates of a particle at the exit face, X = (x, x
, y, y
)
T (with
T denoting
the transpose for a vector or matrix), are related to the values at the entrance
face, X 0 = (x 0 , x
0 , y 0 , y
0 )
T , through a linear transformation
X = MX 0 ,
(1.26)
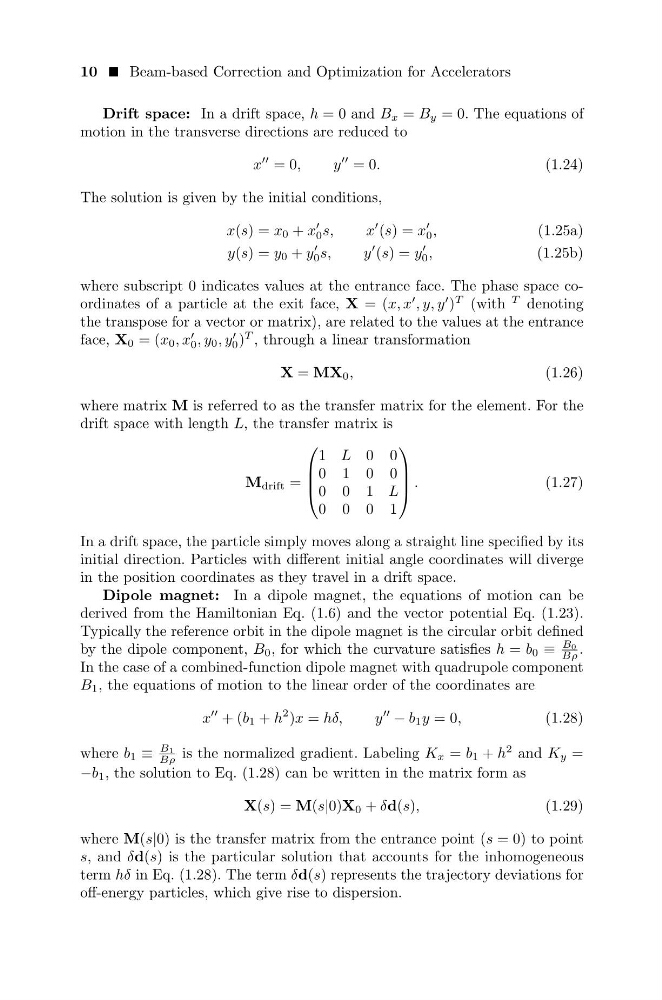
where matrix M is referred to as the transfer matrix for the element. For the
drift space with length L, the transfer matrix is
M drift =
1 L 0 0
0 1 0 0
0 0 1 L
0 0 0 1
.
(1.27)
In a drift space, the particle simply moves along a straight line specified by its
initial direction. Particles with different initial angle coordinates will diverge
in the position coordinates as they travel in a drift space.
Dipole magnet: In a dipole magnet, the equations of motion can be
derived from the Hamiltonian Eq. (1.6) and the vector potential Eq. (1.23).
Typically the reference orbit in the dipole magnet is the circular orbit defined
by the dipole component, B 0 , for which the curvature satisfies h = b 0 ≡
B0
Bρ .
In the case of a combined-function dipole magnet with quadrupole component
B 1 , the equations of motion to the linear order of the coordinates are
x
+ (b 1 + h
2 )x = hδ,
y
− b 1 y = 0,
(1.28)
where b 1 ≡
B1
Bρ is the normalized gradient. Labeling K x = b 1 + h
2 and K y =
−b 1 , the solution to Eq. (1.28) can be written in the matrix form as
X(s) = M(s|0)X 0 + δd(s),
(1.29)
where M(s|0) is the transfer matrix from the entrance point (s = 0) to point
s, and δd(s) is the particular solution that accounts for the inhomogeneous
term hδ in Eq. (1.28). The term δd(s) represents the trajectory deviations for
off-energy particles, which give rise to dispersion.