

Linear optics measurement and correction - I 103
to define the step kick angle change as the unit angle. Then in Eq. (4.23) σ ij
is replaced with σ i and the matrix elements are interpreted as orbit shifts in
length unit (mm or m). The function χ
2 depends on the lattice parameters
through R
model and on the measurement parameters (gains and rolls) through
R
meas . The objective of the least-square fitting is to minimize χ
2 .
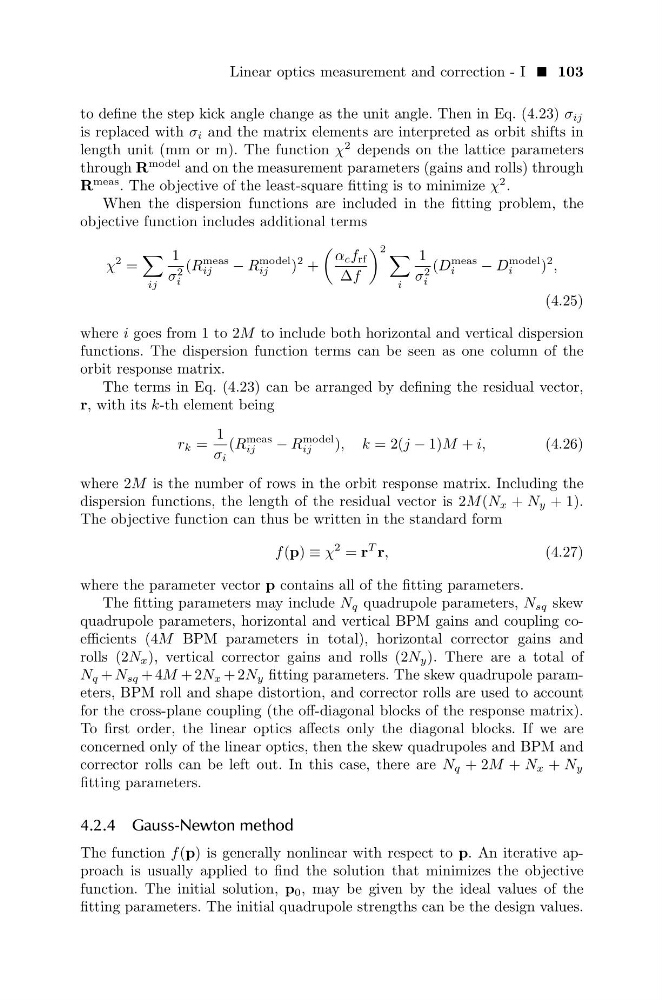
When the dispersion functions are included in the fitting problem, the
objective function includes additional terms
χ
2 =
ij
1
σ 2
i
(R
meas
ij
− R
model
ij
)
2 +
α c f rf
∆f
2
i
1
σ 2
i
(D
meas
i
− D
model
i
)
2 ,
(4.25)
where i goes from 1 to 2M to include both horizontal and vertical dispersion
functions. The dispersion function terms can be seen as one column of the
orbit response matrix.
The terms in Eq. (4.23) can be arranged by defining the residual vector,
r, with its k-th element being
r k =
1
σ i
(R
meas
ij
− R
model
ij
), k = 2(j − 1)M + i,
(4.26)
where 2M is the number of rows in the orbit response matrix. Including the
dispersion functions, the length of the residual vector is 2M (N x + N y + 1).
The objective function can thus be written in the standard form
f (p) ≡ χ
2 = r
T r,
(4.27)
where the parameter vector p contains all of the fitting parameters.
The fitting parameters may include N q quadrupole parameters, N sq skew
quadrupole parameters, horizontal and vertical BPM gains and coupling coefficients (4M BPM parameters in total), horizontal corrector gains and
rolls (2N x ), vertical corrector gains and rolls (2N y ). There are a total of
N q + N sq + 4M + 2N x + 2N y fitting parameters. The skew quadrupole parameters, BPM roll and shape distortion, and corrector rolls are used to account
for the cross-plane coupling (the off-diagonal blocks of the response matrix).
To first order, the linear optics affects only the diagonal blocks. If we are
concerned only of the linear optics, then the skew quadrupoles and BPM and
corrector rolls can be left out. In this case, there are N q + 2M + N x + N y
fitting parameters.
4.2.4 Gauss-Newton method
The function f (p) is generally nonlinear with respect to p. An iterative approach is usually applied to find the solution that minimizes the objective
function. The initial solution, p 0 , may be given by the ideal values of the
fitting parameters. The initial quadrupole strengths can be the design values.