

2.2 Image Feature Matching Experiment of RFID System Physical Anti-Collision
49
their surroundings. It is represented by a vector descriptor of 4 × 4 × 8 = 128 dimensions. Firstly, the image region required by the descriptor is determined. Secondly,
change the coordinate Angle and take the main direction of the key point as the
X-axis direction; then, the gradient amplitude and gradient direction of each pixel
in the image region are calculated, and the histogram of pixel is generated. Finally,
the vector elements are normalized to limit the gradient amplitude on the histogram
below a threshold.
After you have completed the above steps, you can make a key point match
between the reference graph and the observation graph. In general, the key point
matching is mainly based on the key point feature of the reference image.
2.2.2 Image Feature Matching Based on SURF Algorithm
SURF algorithm is fast and robust. SURF algorithm can well deal with the matching
problem between the reference image and the observation image in different situations, such as rotation, zoom, and brightness change. Actually, SURF algorithm is
based on SIFT algorithm using the Hessian matrix to improve the speed, robustness
enhancement mainly because using the Haar wavelet transform, the algorithm can
be used for 3 d reconstruction in the field of machine vision, etc. The realization
process of SURF algorithm mainly consists of feature point generation and feature
point description.
(1) Generate feature points
Hessian matrix is a matrix composed of the second partial derivatives of a multivariate
function, and is also an important part of SURF algorithm. The local maximum value
of the determinant of the matrix is the position of the key point. The box filter is a
tool to solve the arithmetic of adding and subtracting pixels in the neighborhood.
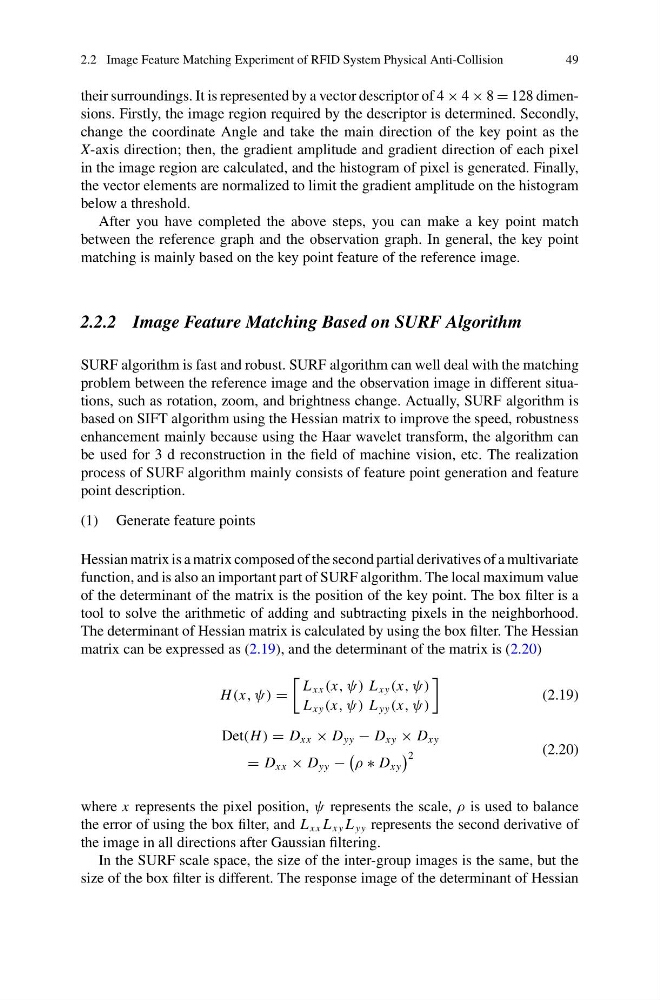
The determinant of Hessian matrix is calculated by using the box filter. The Hessian
matrix can be expressed as (2.19), and the determinant of the matrix is (2.20)
H (x, ψ) =
L xx (x, ψ) L xy (x, ψ)
L xy (x, ψ) L yy (x, ψ)
(2.19)
Det(H ) = D xx × D yy − D xy × D xy
= D xx × D yy −
ρ ∗ D xy
2
(2.20)
where x represents the pixel position, ψ represents the scale, ρ is used to balance
the error of using the box filter, and L xx L xy L yy represents the second derivative of
the image in all directions after Gaussian filtering.
In the SURF scale space, the size of the inter-group images is the same, but the
size of the box filter is different. The response image of the determinant of Hessian