

2.2 Image Feature Matching Experiment of RFID System Physical Anti-Collision
47
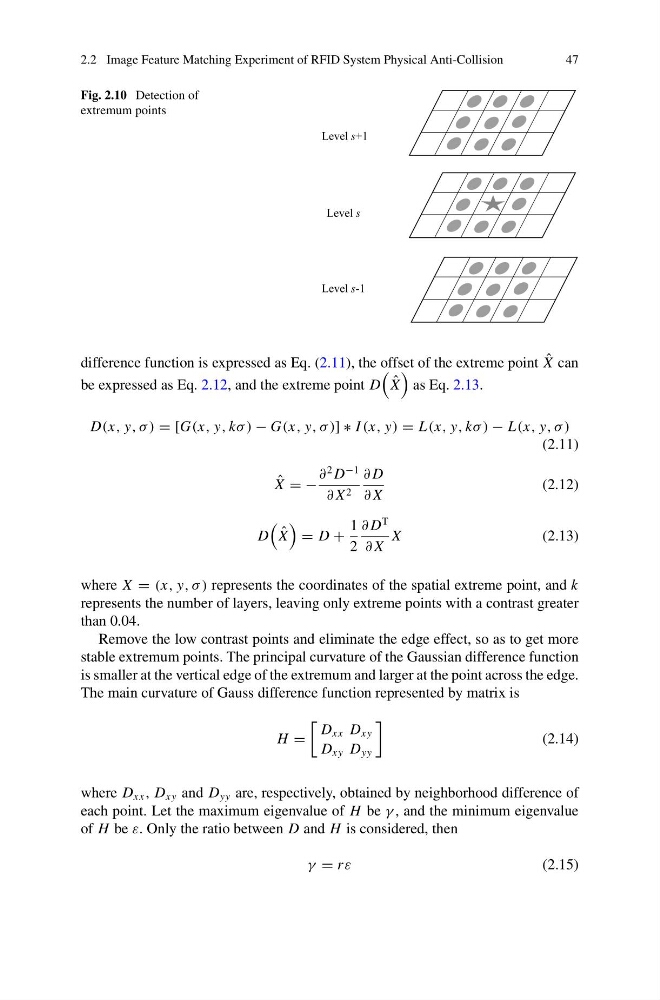
Fig. 2.10 Detection of
extremum points
difference function is expressed as Eq. (2.11), the offset of the extreme point ˆ
X can
be expressed as Eq. 2.12, and the extreme point D
ˆ
X
as Eq. 2.13.
D(x, y, σ ) = [G(x, y, kσ ) − G(x, y, σ )] ∗ I (x, y) = L(x, y, kσ ) − L(x, y, σ )
(2.11)
ˆ
X = −
∂
2 D
−1
∂ X 2
∂ D
∂ X
(2.12)
D
ˆ
X
= D +
1
2
∂ D
T
∂ X
X
(2.13)
where X = (x, y, σ ) represents the coordinates of the spatial extreme point, and k
represents the number of layers, leaving only extreme points with a contrast greater
than 0.04.
Remove the low contrast points and eliminate the edge effect, so as to get more
stable extremum points. The principal curvature of the Gaussian difference function
is smaller at the vertical edge of the extremum and larger at the point across the edge.
The main curvature of Gauss difference function represented by matrix is
H =
D xx D xy
D xy D yy
(2.14)
where D xx , D xy and D yy are, respectively, obtained by neighborhood difference of
each point. Let the maximum eigenvalue of H be γ , and the minimum eigenvalue
of H be ε. Only the ratio between D and H is considered, then
γ = r ε
(2.15)