

228
6 Deep Learning and RFID System Physical Anti-Collision
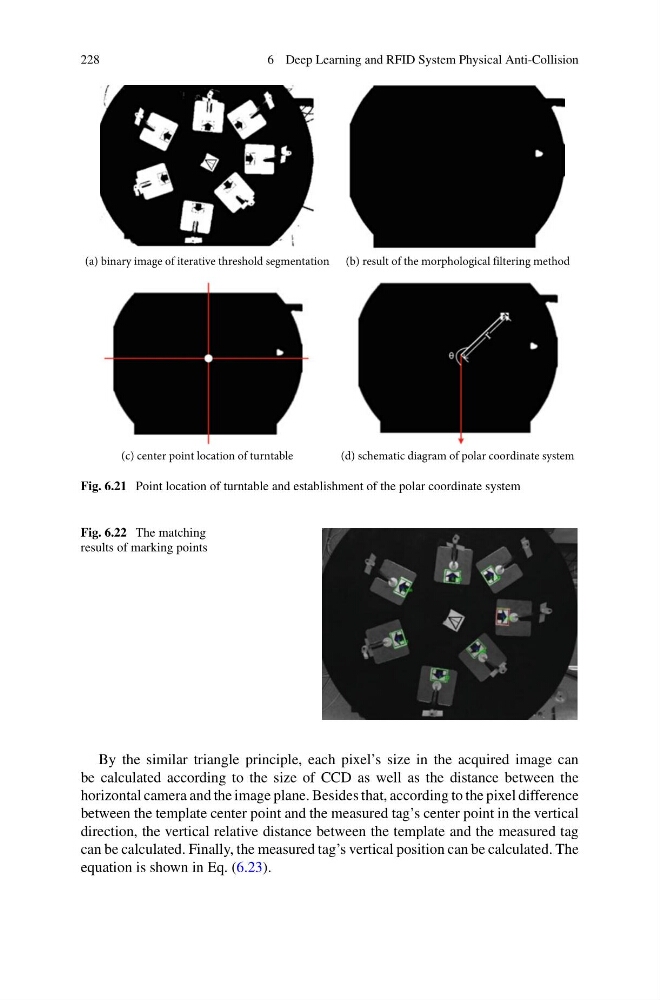
(a) binary image of iterative threshold segmentation (b) result of the morphological filtering method
(c) center point location of turntable
(d) schematic diagram of polar coordinate system
Fig. 6.21 Point location of turntable and establishment of the polar coordinate system
Fig. 6.22 The matching
results of marking points
By the similar triangle principle, each pixel’s size in the acquired image can
be calculated according to the size of CCD as well as the distance between the
horizontal camera and the image plane. Besides that, according to the pixel difference
between the template center point and the measured tag’s center point in the vertical
direction, the vertical relative distance between the template and the measured tag
can be calculated. Finally, the measured tag’s vertical position can be calculated. The
equation is shown in Eq. (6.23).