

226
6 Deep Learning and RFID System Physical Anti-Collision
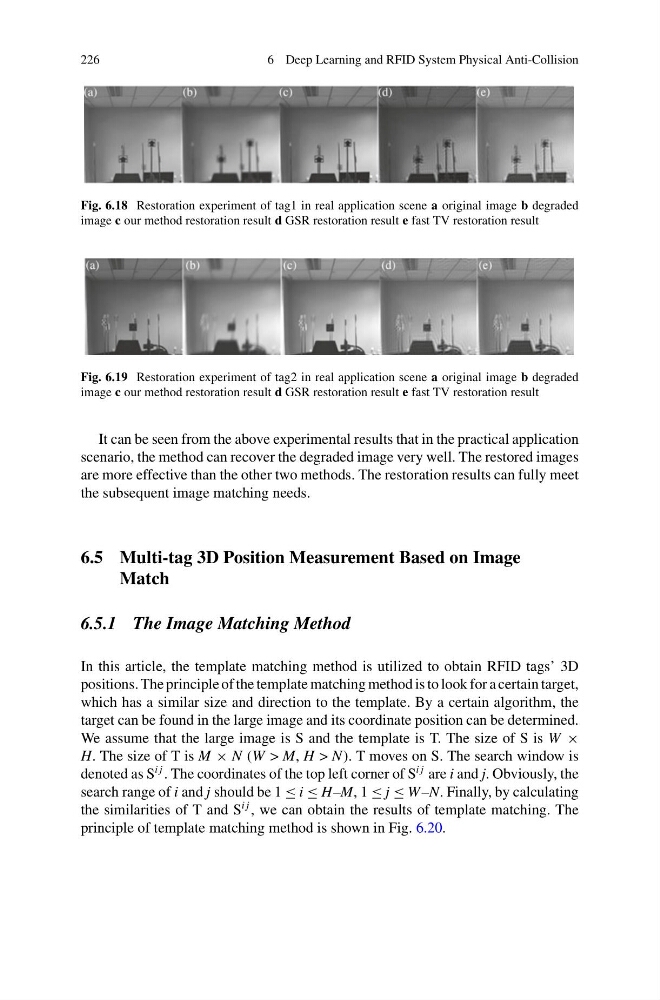
Fig. 6.18 Restoration experiment of tag1 in real application scene a original image b degraded
image c our method restoration result d GSR restoration result e fast TV restoration result
Fig. 6.19 Restoration experiment of tag2 in real application scene a original image b degraded
image c our method restoration result d GSR restoration result e fast TV restoration result
It can be seen from the above experimental results that in the practical application
scenario, the method can recover the degraded image very well. The restored images
are more effective than the other two methods. The restoration results can fully meet
the subsequent image matching needs.
6.5 Multi-tag 3D Position Measurement Based on Image
Match
6.5.1 The Image Matching Method
In this article, the template matching method is utilized to obtain RFID tags’ 3D
positions. The principle of the template matching method is to look for a certain target,
which has a similar size and direction to the template. By a certain algorithm, the
target can be found in the large image and its coordinate position can be determined.
We assume that the large image is S and the template is T. The size of S is W ×
H. The size of T is M × N (W > M, H > N). T moves on S. The search window is
denoted as S
i j . The coordinates of the top left corner of S
i j are i and j. Obviously, the
search range of i and j should be 1 ≤ i ≤ H–M, 1 ≤ j ≤ W –N. Finally, by calculating
the similarities of T and S
i j , we can obtain the results of template matching. The
principle of template matching method is shown in Fig. 6.20.