

216
6 Deep Learning and RFID System Physical Anti-Collision
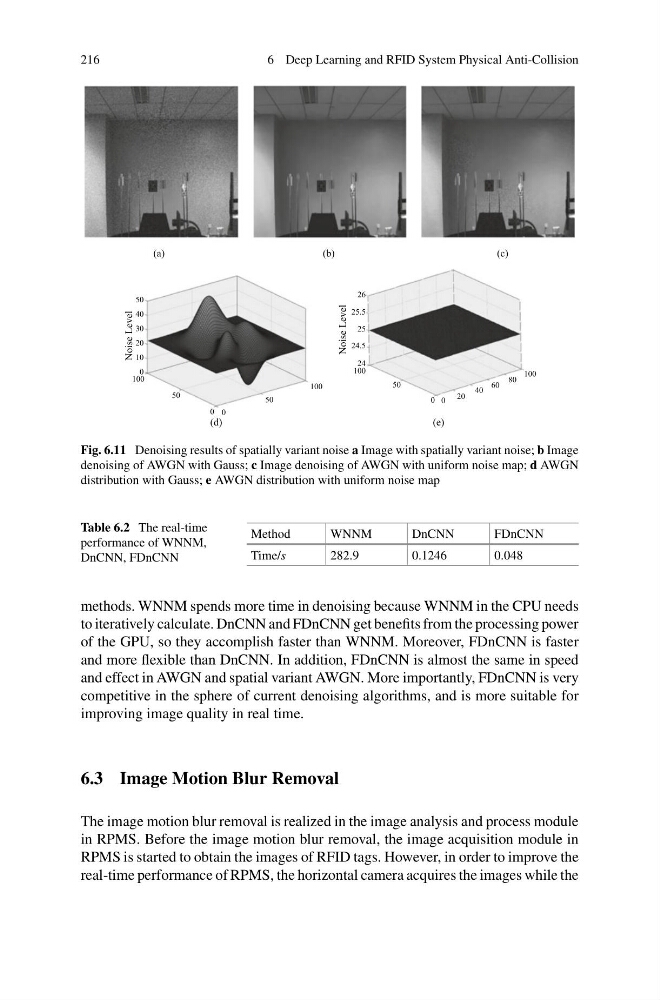
Fig. 6.11 Denoising results of spatially variant noise a Image with spatially variant noise; b Image
denoising of AWGN with Gauss; c Image denoising of AWGN with uniform noise map; d AWGN
distribution with Gauss; e AWGN distribution with uniform noise map
Table 6.2 The real-time
performance of WNNM,
DnCNN, FDnCNN
Method
WNNM
DnCNN
FDnCNN
Time/s
282.9
0.1246
0.048
methods. WNNM spends more time in denoising because WNNM in the CPU needs
to iteratively calculate. DnCNN and FDnCNN get benefits from the processing power
of the GPU, so they accomplish faster than WNNM. Moreover, FDnCNN is faster
and more flexible than DnCNN. In addition, FDnCNN is almost the same in speed
and effect in AWGN and spatial variant AWGN. More importantly, FDnCNN is very
competitive in the sphere of current denoising algorithms, and is more suitable for
improving image quality in real time.
6.3 Image Motion Blur Removal
The image motion blur removal is realized in the image analysis and process module
in RPMS. Before the image motion blur removal, the image acquisition module in
RPMS is started to obtain the images of RFID tags. However, in order to improve the
real-time performance of RPMS, the horizontal camera acquires the images while the