

210
6 Deep Learning and RFID System Physical Anti-Collision
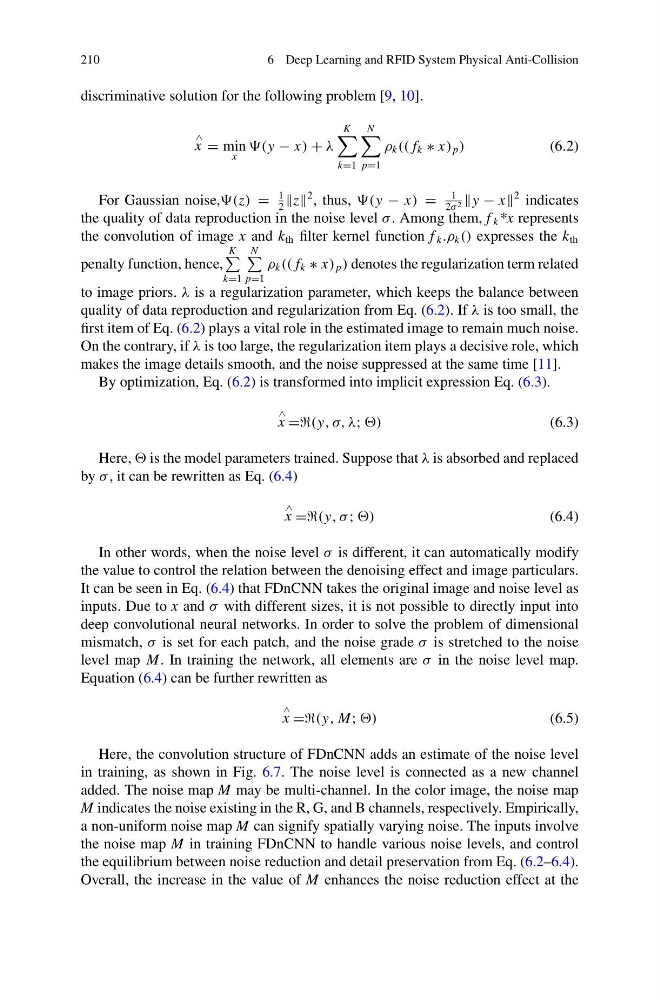
discriminative solution for the following problem [9, 10].
∧
x = min
x
(y − x) + λ
K
k=1
N
p=1
ρ k (( f k ∗ x) p )
(6.2)
For Gaussian noise,(z) =
1
2
z
2 , thus, (y − x) =
1
2σ 2 y − x
2 indicates
the quality of data reproduction in the noise level σ. Among them, f k *x represents
the convolution of image x and k th filter kernel function f k .ρ k () expresses the k th
penalty function, hence,
K
k=1
N
p=1
ρ k (( f k ∗ x) p ) denotes the regularization term related
to image priors. λ is a regularization parameter, which keeps the balance between
quality of data reproduction and regularization from Eq. (6.2). If λ is too small, the
first item of Eq. (6.2) plays a vital role in the estimated image to remain much noise.
On the contrary, if λ is too large, the regularization item plays a decisive role, which
makes the image details smooth, and the noise suppressed at the same time [11].
By optimization, Eq. (6.2) is transformed into implicit expression Eq. (6.3).
∧
x ==(y, σ, λ; )
(6.3)
Here, is the model parameters trained. Suppose that λ is absorbed and replaced
by σ , it can be rewritten as Eq. (6.4)
∧
x ==(y, σ ; )
(6.4)
In other words, when the noise level σ is different, it can automatically modify
the value to control the relation between the denoising effect and image particulars.
It can be seen in Eq. (6.4) that FDnCNN takes the original image and noise level as
inputs. Due to x and σ with different sizes, it is not possible to directly input into
deep convolutional neural networks. In order to solve the problem of dimensional
mismatch, σ is set for each patch, and the noise grade σ is stretched to the noise
level map M. In training the network, all elements are σ in the noise level map.
Equation (6.4) can be further rewritten as
∧
x ==(y, M; )
(6.5)
Here, the convolution structure of FDnCNN adds an estimate of the noise level
in training, as shown in Fig. 6.7. The noise level is connected as a new channel
added. The noise map M may be multi-channel. In the color image, the noise map
M indicates the noise existing in the R, G, and B channels, respectively. Empirically,
a non-uniform noise map M can signify spatially varying noise. The inputs involve
the noise map M in training FDnCNN to handle various noise levels, and control
the equilibrium between noise reduction and detail preservation from Eq. (6.2–6.4).
Overall, the increase in the value of M enhances the noise reduction effect at the