

6.1 RFID Multi-tag 3D Measurement System
203
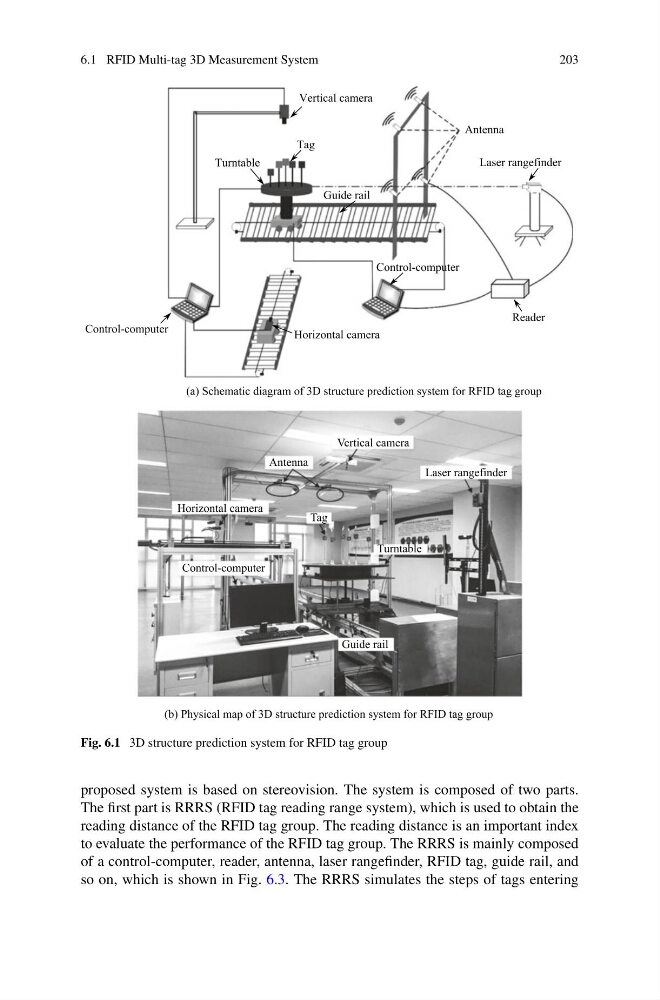
Fig. 6.1 3D structure prediction system for RFID tag group
proposed system is based on stereovision. The system is composed of two parts.
The first part is RRRS (RFID tag reading range system), which is used to obtain the
reading distance of the RFID tag group. The reading distance is an important index
to evaluate the performance of the RFID tag group. The RRRS is mainly composed
of a control-computer, reader, antenna, laser rangefinder, RFID tag, guide rail, and
so on, which is shown in Fig. 6.3. The RRRS simulates the steps of tags entering