

162
5 Optimization Algorithm and RFID System Physical Anti-Collision
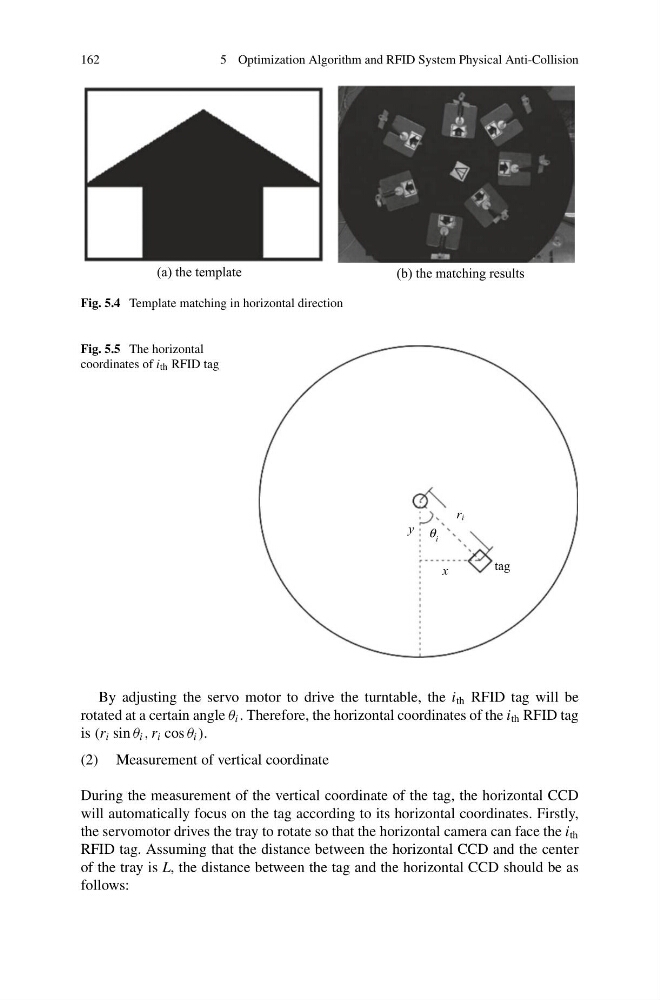
Fig. 5.4 Template matching in horizontal direction
Fig. 5.5 The horizontal
coordinates of i th RFID tag
By adjusting the servo motor to drive the turntable, the i th RFID tag will be
rotated at a certain angle θ i . Therefore, the horizontal coordinates of the i th RFID tag
is (r i sin θ i , r i cos θ i ).
(2) Measurement of vertical coordinate
During the measurement of the vertical coordinate of the tag, the horizontal CCD
will automatically focus on the tag according to its horizontal coordinates. Firstly,
the servomotor drives the tray to rotate so that the horizontal camera can face the i th
RFID tag. Assuming that the distance between the horizontal CCD and the center
of the tray is L, the distance between the tag and the horizontal CCD should be as
follows: