

4.3 RFID Tag Positioning Method
135
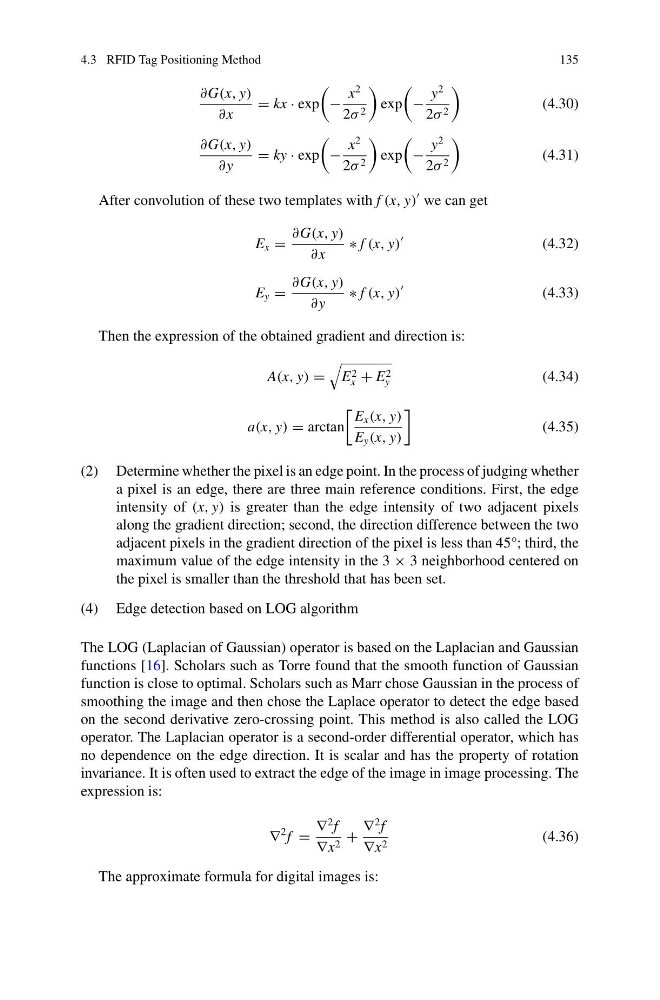
∂G(x, y)
∂x
= kx · exp
−
x
2
2σ 2
exp
−
y
2
2σ 2
(4.30)
∂G(x, y)
∂y
= ky · exp
−
x
2
2σ 2
exp
−
y
2
2σ 2
(4.31)
After convolution of these two templates with f (x, y)
we can get
E x =
∂G(x, y)
∂x
∗ f (x, y)
(4.32)
E y =
∂G(x, y)
∂y
∗ f (x, y)
(4.33)
Then the expression of the obtained gradient and direction is:
A(x, y) =
E 2
x + E 2
y
(4.34)
a(x, y) = arctan
E x (x, y)
E y (x, y)
(4.35)
(2) Determine whether the pixel is an edge point. In the process of judging whether
a pixel is an edge, there are three main reference conditions. First, the edge
intensity of (x, y) is greater than the edge intensity of two adjacent pixels
along the gradient direction; second, the direction difference between the two
adjacent pixels in the gradient direction of the pixel is less than 45°; third, the
maximum value of the edge intensity in the 3 × 3 neighborhood centered on
the pixel is smaller than the threshold that has been set.
(4) Edge detection based on LOG algorithm
The LOG (Laplacian of Gaussian) operator is based on the Laplacian and Gaussian
functions [16]. Scholars such as Torre found that the smooth function of Gaussian
function is close to optimal. Scholars such as Marr chose Gaussian in the process of
smoothing the image and then chose the Laplace operator to detect the edge based
on the second derivative zero-crossing point. This method is also called the LOG
operator. The Laplacian operator is a second-order differential operator, which has
no dependence on the edge direction. It is scalar and has the property of rotation
invariance. It is often used to extract the edge of the image in image processing. The
expression is:
∇
2 f =
∇
2 f
∇x 2 +
∇
2 f
∇x 2
(4.36)
The approximate formula for digital images is: