

60
M.-L. Bes , liu-Gherghescu et al.
a cylindrical joint and acted by a harmonic-type force at this point. The equations
which offer the shapes of the deformed beams, the elongations of the beams and the
horizontal force that appears in the beams are presented. A numerical example of
such system is discussed, and some conclusions end the paper.
2 Mechanical System
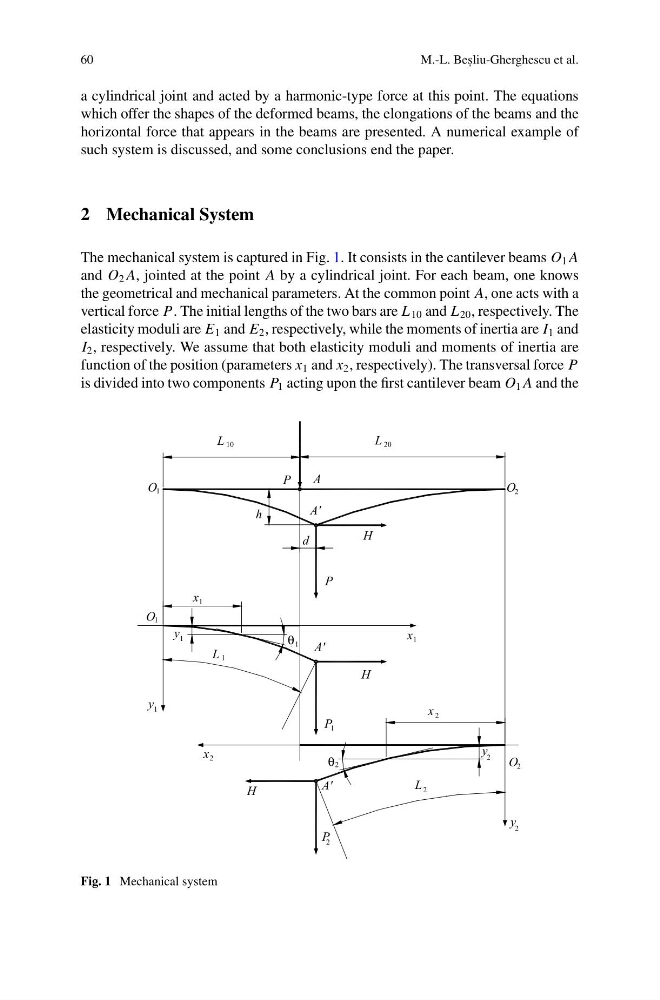
The mechanical system is captured in Fig. 1. It consists in the cantilever beams O 1 A
and O 2 A, jointed at the point A by a cylindrical joint. For each beam, one knows
the geometrical and mechanical parameters. At the common point A, one acts with a
vertical force P. The initial lengths of the two bars are L 10 and L 20 , respectively. The
elasticity moduli are E 1 and E 2 , respectively, while the moments of inertia are I 1 and
I 2 , respectively. We assume that both elasticity moduli and moments of inertia are
function of the position (parameters x 1 and x 2 , respectively). The transversal force P
is divided into two components P 1 acting upon the first cantilever beam O 1 A and the
P
P
H
P
H
P
H
O
x
x
y
y
1
2
2
2
1
1
L
L
2
10
20
A
A'
A'
A'
d
θ 1
L 1
L 2
θ2
O 1
O 1
O 2
h
x 1
y 1
x 2
y 2
Fig. 1 Mechanical system