

Vibrations of the Mass Variable Systems
33
ξ =
dI ξ
dt
(Ω 2ξ − Ω ξ ), η =
dI η
dt
(Ω 2η − Ω η ), ζ =
dI ζ
dt
(Ω 2ζ − Ω ζ )
(43)
Equations (40) and (42) are six scalar differential equations of motion of the body
with variable mass.
4 Vibration of the Oscillator with Continual Mass Variation
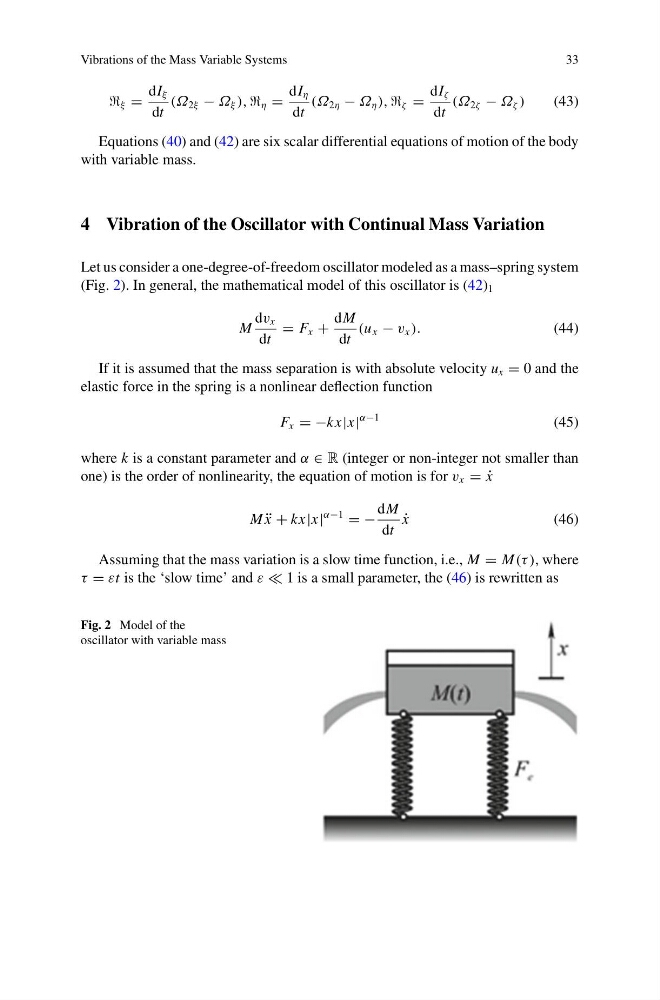
Let us consider a one-degree-of-freedom oscillator modeled as a mass–spring system
(Fig. 2). In general, the mathematical model of this oscillator is (42) 1
M
dv x
dt
= F x +
dM
dt
(u x − v x ).
(44)
If it is assumed that the mass separation is with absolute velocity u x = 0 and the
elastic force in the spring is a nonlinear deflection function
F x = −kx|x|
α−1
(45)
where k is a constant parameter and α ∈ R (integer or non-integer not smaller than
one) is the order of nonlinearity, the equation of motion is for v x = ˙
x
M ¨
x + kx|x|
α−1
= −
dM
dt
˙
x
(46)
Assuming that the mass variation is a slow time function, i.e., M = M(τ ), where
τ = εt is the ‘slow time’ and ε 1 is a small parameter, the (46) is rewritten as
Fig. 2 Model of the
oscillator with variable mass