

398
M. Dragomir et al.
χ = ˜
xl
2
ρ A
E I
.
(8)
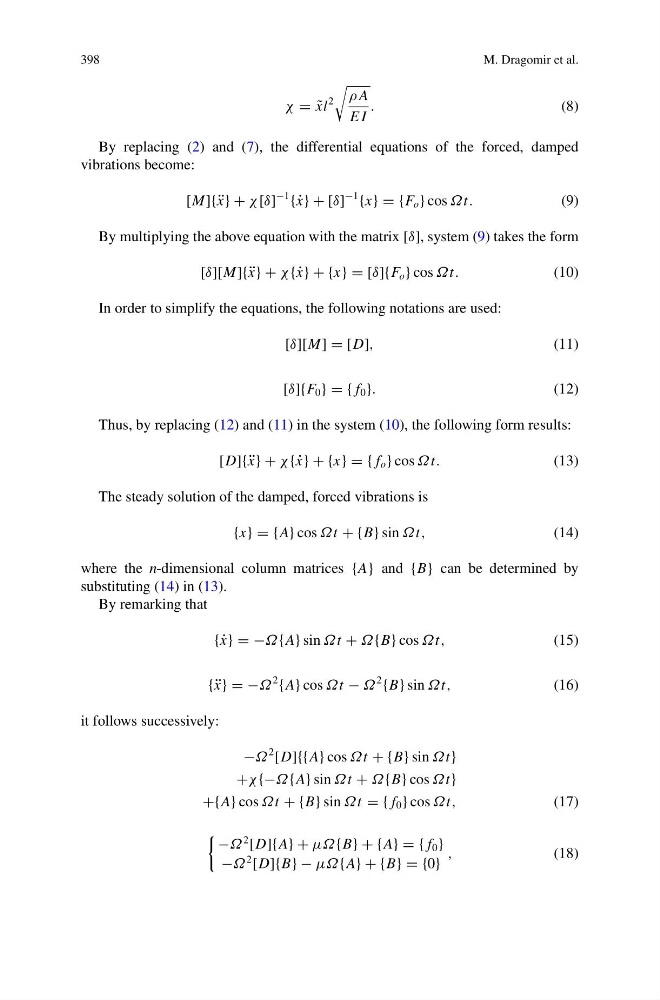
By replacing (2) and (7), the differential equations of the forced, damped
vibrations become:
[M]{ ¨
x} + χ [δ]
−1
{ ˙
x} + [δ]
−1
{x} = {F o } cos Ωt.
(9)
By multiplying the above equation with the matrix [δ], system (9) takes the form
[δ][M]{ ¨
x} + χ { ˙
x} + {x} = [δ]{F o } cos Ωt.
(10)
In order to simplify the equations, the following notations are used:
[δ][M] = [D],
(11)
[δ]{F 0 } = { f 0 }.
(12)
Thus, by replacing (12) and (11) in the system (10), the following form results:
[D]{ ¨
x} + χ { ˙
x} + {x} = { f o } cos Ωt.
(13)
The steady solution of the damped, forced vibrations is
{x} = {A} cos Ωt + {B} sin Ωt,
(14)
where the n-dimensional column matrices {A} and {B} can be determined by
substituting (14) in (13).
By remarking that
{ ˙
x} = −Ω{A} sin Ωt + Ω{B} cos Ωt,
(15)
{ ¨
x} = −Ω
2
{A} cos Ωt − Ω
2
{B} sin Ωt,
(16)
it follows successively:
−Ω
2 [D]{{A} cos Ωt + {B} sin Ωt}
+χ {−Ω{A} sin Ωt + Ω{B} cos Ωt}
+{A} cos Ωt + {B} sin Ωt = { f 0 } cos Ωt,
(17)
−Ω
2 [D]{A} + μΩ{B} + {A} = { f 0 }
−Ω
2 [D]{B} − μΩ{A} + {B} = {0}
,
(18)