

270
C.-G. Alionte et al.
a)
b)
c)
d)
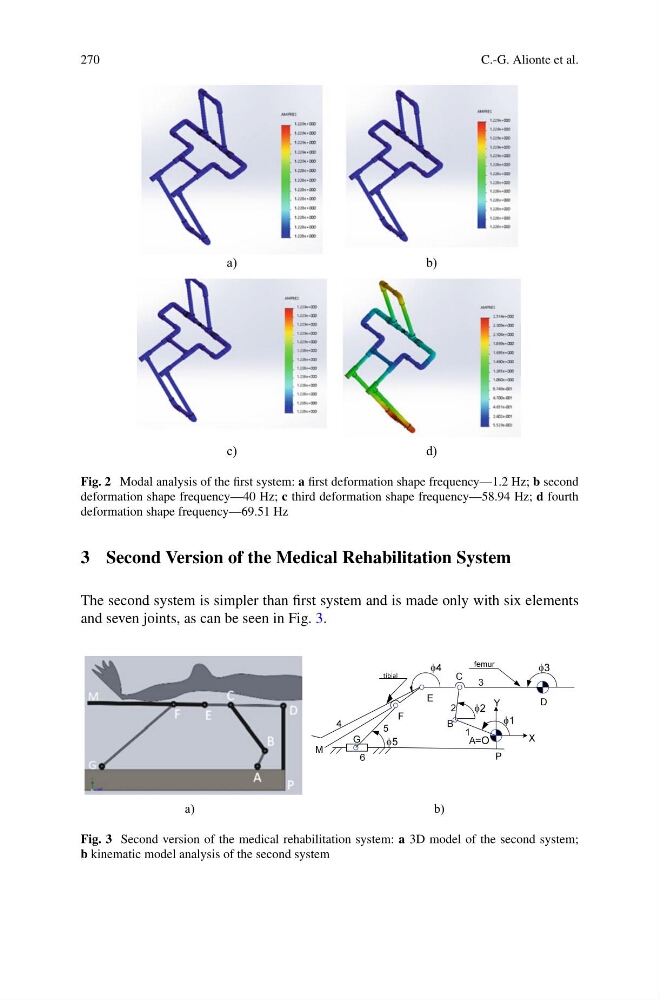
Fig. 2 Modal analysis of the first system: a first deformation shape frequency—1.2 Hz; b second
deformation shape frequency—40 Hz; c third deformation shape frequency—58.94 Hz; d fourth
deformation shape frequency—69.51 Hz
3 Second Version of the Medical Rehabilitation System
The second system is simpler than first system and is made only with six elements
and seven joints, as can be seen in Fig. 3.
a)
b)
Fig. 3 Second version of the medical rehabilitation system: a 3D model of the second system;
b kinematic model analysis of the second system