

Modelling of Frictional Contacts in 3D Dynamics …
5
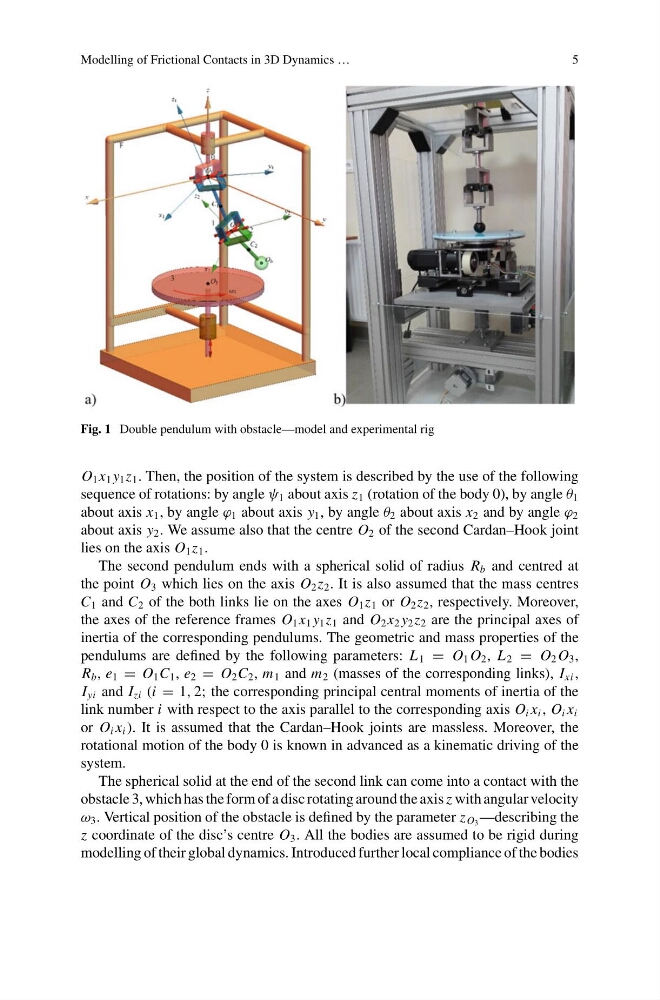
Fig. 1 Double pendulum with obstacle—model and experimental rig
O 1 x 1 y 1 z 1 . Then, the position of the system is described by the use of the following
sequence of rotations: by angle ψ 1 about axis z 1 (rotation of the body 0), by angle θ 1
about axis x 1 , by angle ϕ 1 about axis y 1 , by angle θ 2 about axis x 2 and by angle ϕ 2
about axis y 2 . We assume also that the centre O 2 of the second Cardan–Hook joint
lies on the axis O 1 z 1 .
The second pendulum ends with a spherical solid of radius R b and centred at
the point O 3 which lies on the axis O 2 z 2 . It is also assumed that the mass centres
C 1 and C 2 of the both links lie on the axes O 1 z 1 or O 2 z 2 , respectively. Moreover,
the axes of the reference frames O 1 x 1 y 1 z 1 and O 2 x 2 y 2 z 2 are the principal axes of
inertia of the corresponding pendulums. The geometric and mass properties of the
pendulums are defined by the following parameters: L 1 = O 1 O 2 , L 2 = O 2 O 3 ,
R b , e 1 = O 1 C 1 , e 2 = O 2 C 2 , m 1 and m 2 (masses of the corresponding links), I xi ,
I yi and I zi (i = 1, 2; the corresponding principal central moments of inertia of the
link number i with respect to the axis parallel to the corresponding axis O i x i , O i x i
or O i x i ). It is assumed that the Cardan–Hook joints are massless. Moreover, the
rotational motion of the body 0 is known in advanced as a kinematic driving of the
system.
The spherical solid at the end of the second link can come into a contact with the
obstacle 3, which has the form of a disc rotating around the axis z with angular velocity
ω 3 . Vertical position of the obstacle is defined by the parameter z O 3 —describing the
z coordinate of the disc’s centre O 3 . All the bodies are assumed to be rigid during
modelling of their global dynamics. Introduced further local compliance of the bodies