

Fundamental concepts 7
The output displacement at the prismatic joint is therefore uniquely
decided by the input angle at the revolute joint.
Due to the fact that the Kutzbach criterion given in Eq. (2.1) considers
only the topological information of a linkage, it can sometimes give misleading results. Take the RSSP linkage in Figure 2.1(b) as an example. It
has four links and four joints: one revolute, two spherical and one prismatic joint. Therefore,
.
This contradicts with the fact that there is a unique output displacement at
the prismatic joint for any given value of the input variable at the revolute
joint. Then, where is the second mobility? Examination of the linkage reveals
that the coupler link that bridges two spherical joints is free to spin about
the line through the centres of the spherical joints. Such motion, called an
idle degree of freedom, can take place in any position of the linkage without
affecting the real input and output relationship. So when idle degrees of
freedom exist the Kutzbach criterion gives the result that the number of
mobility is greater than the number of useful degrees of freedom.
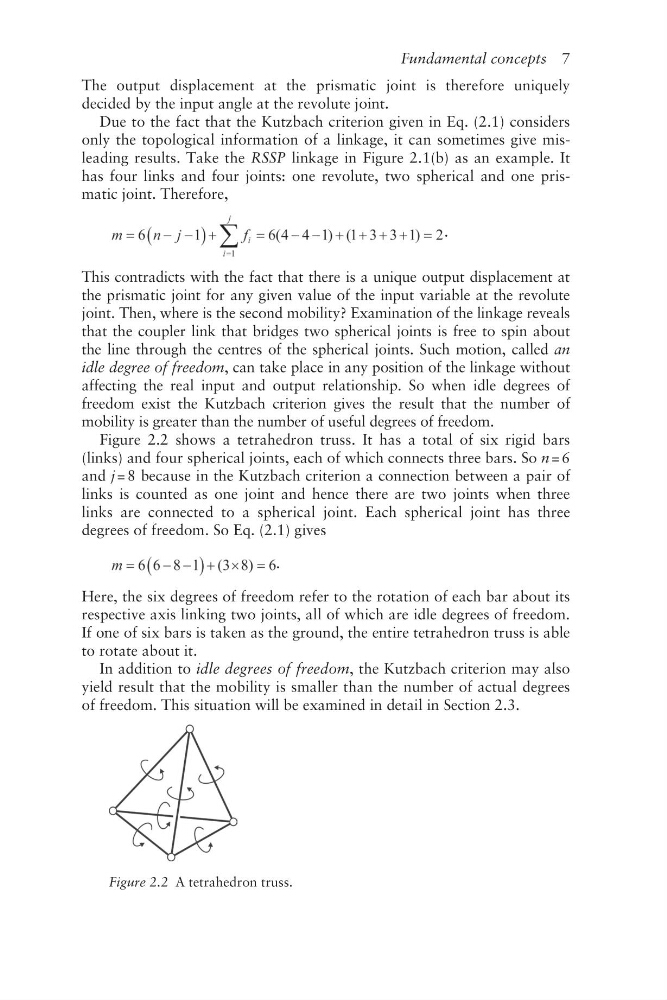
Figure 2.2 shows a tetrahedron truss. It has a total of six rigid bars
(links) and four spherical joints, each of which connects three bars. So n = 6
and j = 8 because in the Kutzbach criterion a connection between a pair of
links is counted as one joint and hence there are two joints when three
links are connected to a spherical joint. Each spherical joint has three
degrees of freedom. So Eq. (2.1) gives
.
Here, the six degrees of freedom refer to the rotation of each bar about its
respective axis linking two joints, all of which are idle degrees of freedom.
If one of six bars is taken as the ground, the entire tetrahedron truss is able
to rotate about it.
In addition to idle degrees of freedom, the Kutzbach criterion may also
yield result that the mobility is smaller than the number of actual degrees
of freedom. This situation will be examined in detail in Section 2.3.
Figure 2.2 A tetrahedron truss.