

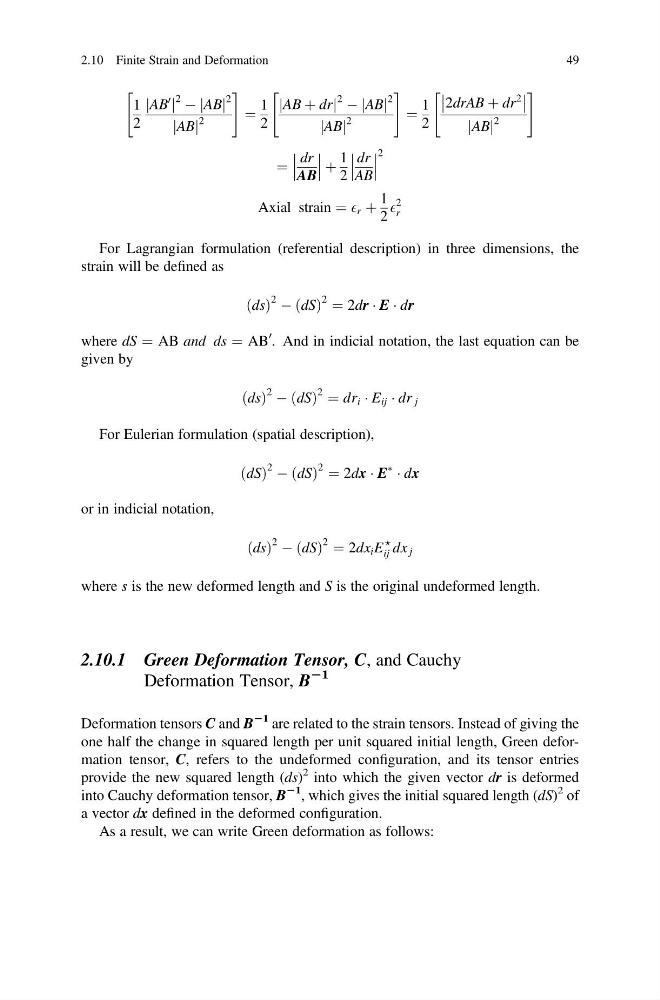
1
2
AB
0
j j
2 À AB
j j
2
AB
j j
2
"
#
¼
1
2
AB þ dr
j
j
2 À AB
j j
2
AB
j j
2
"
#
¼
1
2
2drAB þ dr
2
AB
j j
2
"
#
¼
dr
AB
þ
1
2
dr
AB
2
Axial strain ¼ E r þ
1
2
E
2
r
For Lagrangian formulation (referential description) in three dimensions, the
strain will be defined as
ds
ð Þ
2 À dS
ð Þ
2 ¼ 2dr Á E Á dr
where dS ¼ AB and ds ¼ AB
0
. And in indicial notation, the last equation can be
given by
ds
ð Þ
2 À dS
ð Þ
2 ¼ dr i Á E ij Á dr j
For Eulerian formulation (spatial description),
dS
ð Þ
2 À dS
ð Þ
2 ¼ 2dx Á E
Ã
Á dx
or in indicial notation,
ds
ð Þ
2 À dS
ð Þ
2 ¼ 2dx i E
⋆
ij dx j
where s is the new deformed length and S is the original undeformed length.
2.10.1 Green Deformation Tensor, C, and Cauchy
Deformation Tensor, B
21
Deformation tensors C and B
21 are related to the strain tensors. Instead of giving the
one half the change in squared length per unit squared initial length, Green deformation tensor, C, refers to the undeformed configuration, and its tensor entries
provide the new squared length (ds)
2 into which the given vector dr is deformed
into Cauchy deformation tensor, B
21 , which gives the initial squared length (dS)
2 of
a vector dx defined in the deformed configuration.
As a result, we can write Green deformation as follows:
2.10 Finite Strain and Deformation
49
2
AB
0
j j
2 À AB
j j
2
AB
j j
2
"
#
¼
1
2
AB þ dr
j
j
2 À AB
j j
2
AB
j j
2
"
#
¼
1
2
2drAB þ dr
2
AB
j j
2
"
#
¼
dr
AB
þ
1
2
dr
AB
2
Axial strain ¼ E r þ
1
2
E
2
r
For Lagrangian formulation (referential description) in three dimensions, the
strain will be defined as
ds
ð Þ
2 À dS
ð Þ
2 ¼ 2dr Á E Á dr
where dS ¼ AB and ds ¼ AB
0
. And in indicial notation, the last equation can be
given by
ds
ð Þ
2 À dS
ð Þ
2 ¼ dr i Á E ij Á dr j
For Eulerian formulation (spatial description),
dS
ð Þ
2 À dS
ð Þ
2 ¼ 2dx Á E
Ã
Á dx
or in indicial notation,
ds
ð Þ
2 À dS
ð Þ
2 ¼ 2dx i E
⋆
ij dx j
where s is the new deformed length and S is the original undeformed length.
2.10.1 Green Deformation Tensor, C, and Cauchy
Deformation Tensor, B
21
Deformation tensors C and B
21 are related to the strain tensors. Instead of giving the
one half the change in squared length per unit squared initial length, Green deformation tensor, C, refers to the undeformed configuration, and its tensor entries
provide the new squared length (ds)
2 into which the given vector dr is deformed
into Cauchy deformation tensor, B
21 , which gives the initial squared length (dS)
2 of
a vector dx defined in the deformed configuration.
As a result, we can write Green deformation as follows:
2.10 Finite Strain and Deformation
49