

x ¼ x A þ x B À x A
ð
Þ r
y ¼ y A þ y B À y A
ð
Þ r
We will derive the finite strain formulation using Malvern (1969) formulation and
notation with few changes. We will define deformation gradient tensor F as a tensor
that its components are the partial derivatives between the referential (Lagrangian)
coordinate axes and local (material) coordinates. F, the deformation gradient tensor,
will be defined in terms of the undeformed configuration. x, y, z referential coordinates are represented by bold X. Local (material) coordinates are represented by
bold r.
The relation between the referential coordinates and local (material) coordinates
are given by:
dX ¼ F Á dr or dr ¼ dX Á F
T
or in indicial matrix notation
dx i
f g ¼
∂x i
∂r j
!
dr j
È É
Therefore,
O
A
B
dr
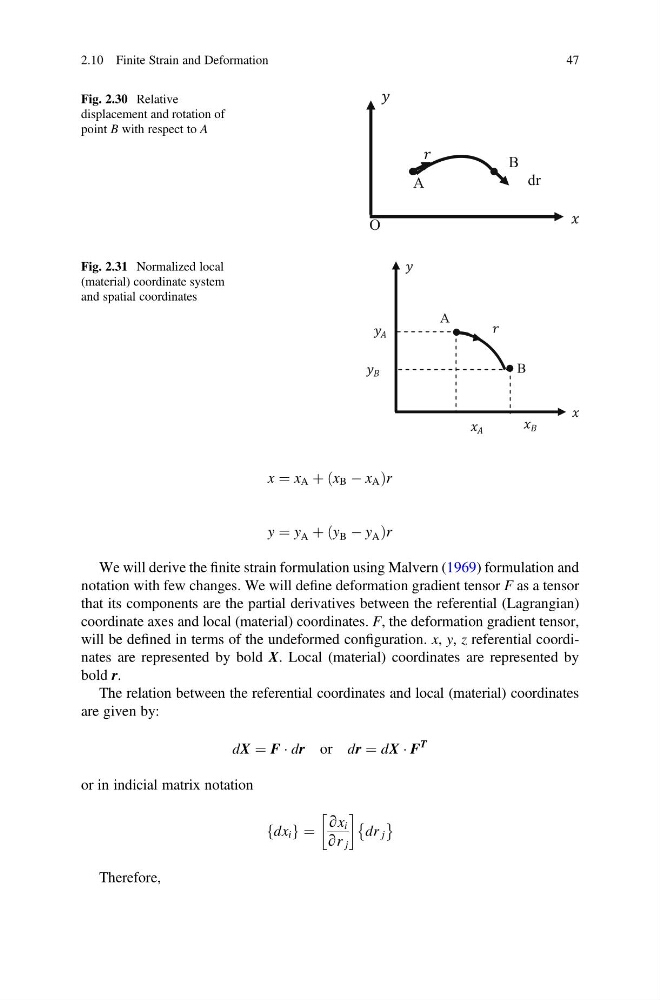
Fig. 2.30 Relative
displacement and rotation of
point B with respect to A
A
B
Fig. 2.31 Normalized local
(material) coordinate system
and spatial coordinates
2.10 Finite Strain and Deformation
47
ð
Þ r
y ¼ y A þ y B À y A
ð
Þ r
We will derive the finite strain formulation using Malvern (1969) formulation and
notation with few changes. We will define deformation gradient tensor F as a tensor
that its components are the partial derivatives between the referential (Lagrangian)
coordinate axes and local (material) coordinates. F, the deformation gradient tensor,
will be defined in terms of the undeformed configuration. x, y, z referential coordinates are represented by bold X. Local (material) coordinates are represented by
bold r.
The relation between the referential coordinates and local (material) coordinates
are given by:
dX ¼ F Á dr or dr ¼ dX Á F
T
or in indicial matrix notation
dx i
f g ¼
∂x i
∂r j
!
dr j
È É
Therefore,
O
A
B
dr
Fig. 2.30 Relative
displacement and rotation of
point B with respect to A
A
B
Fig. 2.31 Normalized local
(material) coordinate system
and spatial coordinates
2.10 Finite Strain and Deformation
47