

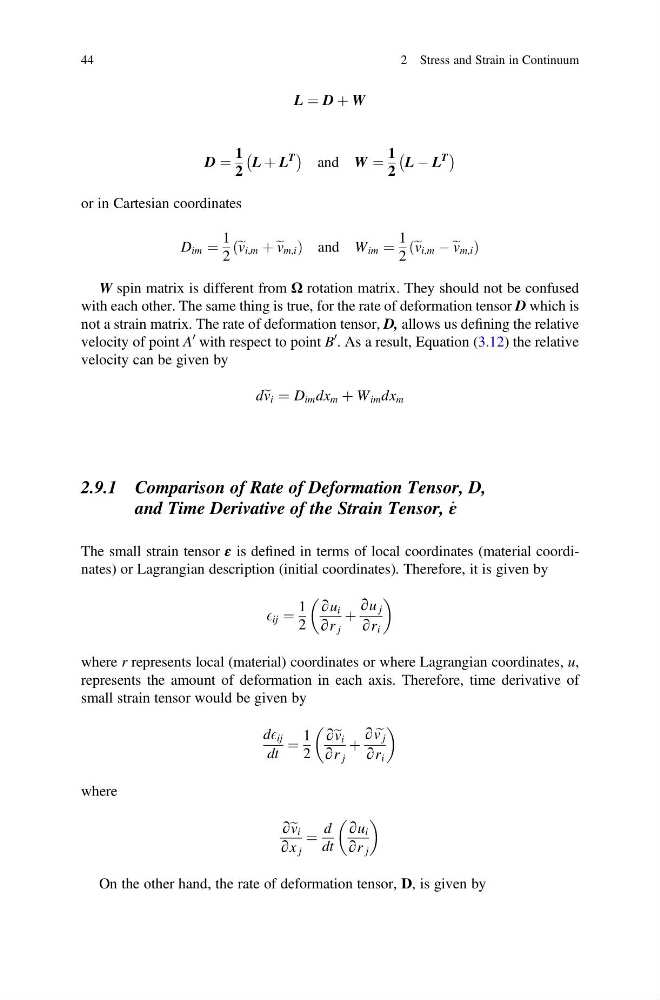
L ¼ D þ W
D ¼
1
2
L þ L
T
À
Á
and W ¼
1
2
L À L
T
À
Á
or in Cartesian coordinates
D im ¼
1
2
e v i,m þ e v m,i
ð
Þ and W im ¼
1
2
e v i,m À e v m,i
ð
Þ
W spin matrix is different from Ω rotation matrix. They should not be confused
with each other. The same thing is true, for the rate of deformation tensor D which is
not a strain matrix. The rate of deformation tensor, D, allows us defining the relative
velocity of point A
0 with respect to point B
0 . As a result, Equation (3.12) the relative
velocity can be given by
de v i ¼ D im dx m þ W im dx m
2.9.1 Comparison of Rate of Deformation Tensor, D,
and Time Derivative of the Strain Tensor, _
ε
The small strain tensor ε is defined in terms of local coordinates (material coordinates) or Lagrangian description (initial coordinates). Therefore, it is given by
E ij ¼
1
2
∂u i
∂r j
þ
∂u j
∂r i
where r represents local (material) coordinates or where Lagrangian coordinates, u,
represents the amount of deformation in each axis. Therefore, time derivative of
small strain tensor would be given by
dE ij
dt
¼
1
2
∂e v i
∂r j
þ
∂ e
v j
∂r i
where
∂e v i
∂x j
¼
d
dt
∂u i
∂r j
On the other hand, the rate of deformation tensor, D, is given by
44
2 Stress and Strain in Continuum