

du
dr
dv
dr
dw
dr
8
> > > > > <
> > > > > :
9
> > > > > =
> > > > > ;
¼
∂u
∂x
∂u
∂y
∂u
∂z
∂v
∂x
∂v
∂y
∂v
∂z
∂w
∂x
∂w
∂y
∂w
∂z
2
6
6
6
6
6
6
6
4
3
7
7
7
7
7
7
7
5
dx
dr
dy
dr
dz
dr
8
> > > > > <
> > > > > :
9
> > > > > =
> > > > > ;
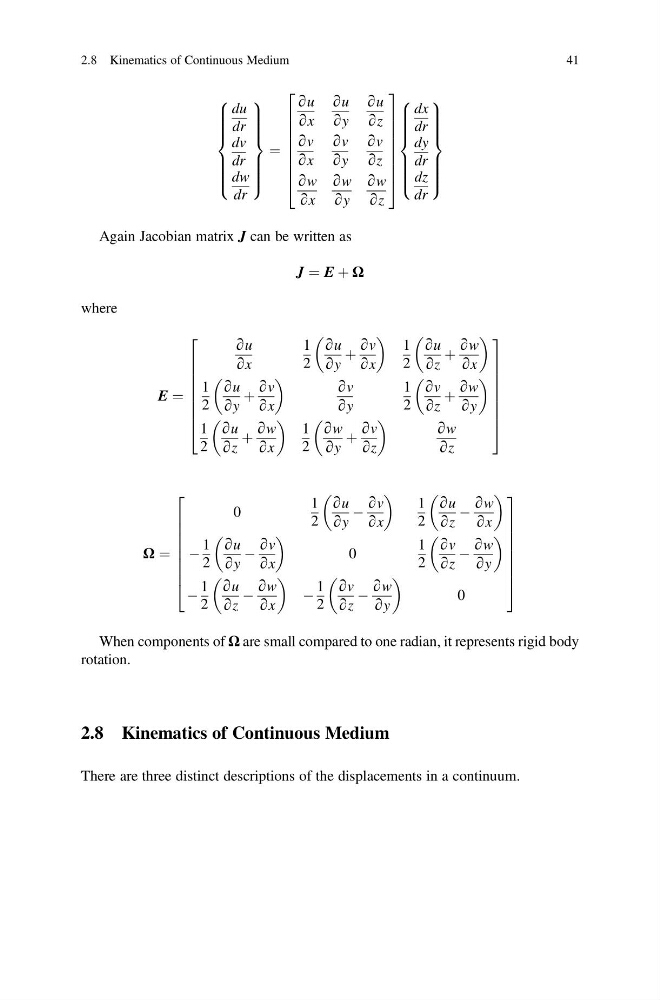
Again Jacobian matrix J can be written as
J ¼ E þ Ω
where
E ¼
∂u
∂x
1
2
∂u
∂y
þ
∂v
∂x
1
2
∂u
∂z
þ
∂w
∂x
1
2
∂u
∂y
þ
∂v
∂x
∂v
∂y
1
2
∂v
∂z
þ
∂w
∂y
1
2
∂u
∂z
þ
∂w
∂x
1
2
∂w
∂y
þ
∂v
∂z
∂w
∂z
2
6
6
6
6
6
6
6
4
3
7
7
7
7
7
7
7
5
Ω ¼
0
1
2
∂u
∂y
À
∂v
∂x
1
2
∂u
∂z
À
∂w
∂x
À
1
2
∂u
∂y
À
∂v
∂x
0
1
2
∂v
∂z
À
∂w
∂y
À
1
2
∂u
∂z
À
∂w
∂x
À
1
2
∂v
∂z
À
∂w
∂y
0
2
6
6
6
6
6
6
6
4
3
7
7
7
7
7
7
7
5
When components of Ω are small compared to one radian, it represents rigid body
rotation.
2.8 Kinematics of Continuous Medium
There are three distinct descriptions of the displacements in a continuum.
2.8 Kinematics of Continuous Medium
41
dr
dv
dr
dw
dr
8
> > > > > <
> > > > > :
9
> > > > > =
> > > > > ;
¼
∂u
∂x
∂u
∂y
∂u
∂z
∂v
∂x
∂v
∂y
∂v
∂z
∂w
∂x
∂w
∂y
∂w
∂z
2
6
6
6
6
6
6
6
4
3
7
7
7
7
7
7
7
5
dx
dr
dy
dr
dz
dr
8
> > > > > <
> > > > > :
9
> > > > > =
> > > > > ;
Again Jacobian matrix J can be written as
J ¼ E þ Ω
where
E ¼
∂u
∂x
1
2
∂u
∂y
þ
∂v
∂x
1
2
∂u
∂z
þ
∂w
∂x
1
2
∂u
∂y
þ
∂v
∂x
∂v
∂y
1
2
∂v
∂z
þ
∂w
∂y
1
2
∂u
∂z
þ
∂w
∂x
1
2
∂w
∂y
þ
∂v
∂z
∂w
∂z
2
6
6
6
6
6
6
6
4
3
7
7
7
7
7
7
7
5
Ω ¼
0
1
2
∂u
∂y
À
∂v
∂x
1
2
∂u
∂z
À
∂w
∂x
À
1
2
∂u
∂y
À
∂v
∂x
0
1
2
∂v
∂z
À
∂w
∂y
À
1
2
∂u
∂z
À
∂w
∂x
À
1
2
∂v
∂z
À
∂w
∂y
0
2
6
6
6
6
6
6
6
4
3
7
7
7
7
7
7
7
5
When components of Ω are small compared to one radian, it represents rigid body
rotation.
2.8 Kinematics of Continuous Medium
There are three distinct descriptions of the displacements in a continuum.
2.8 Kinematics of Continuous Medium
41