

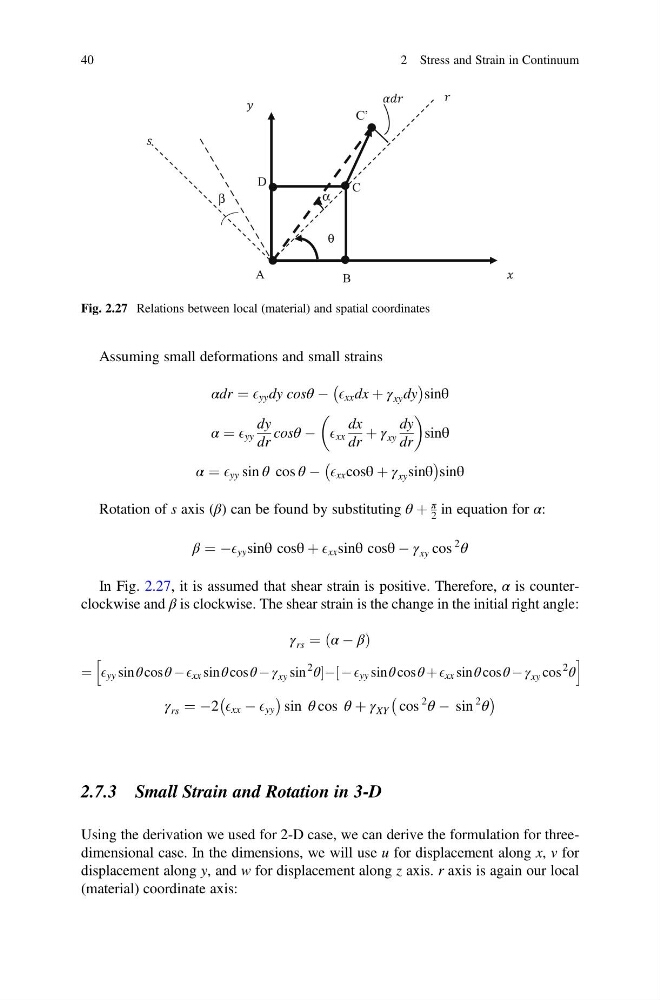
Assuming small deformations and small strains
αdr ¼ E yy dy cosθ À E xx dx þ γ xy dy
À
Á
sinθ
α ¼ E yy
dy
dr
cosθ À E xx
dx
dr
þ γ xy
dy
dr
sinθ
α ¼ E yy sin θ cos θ À E xx cosθ þ γ xy sinθ
À
Á
sinθ
Rotation of s axis (β) can be found by substituting θ þ
π
2 in equation for α:
β ¼ ÀE yy sinθ cosθ þ E xx sinθ cosθ À γ xy cos
2
θ
In Fig. 2.27, it is assumed that shear strain is positive. Therefore, α is counterclockwise and β is clockwise. The shear strain is the change in the initial right angle:
γ rs ¼ α À β
ð
Þ
¼ E yy sin θ cos θ À E xx sin θ cos θ À γ xy sin
2
θ À
½ÀE yy sin θ cos θ þ E xx sin θ cos θ À γ xy cos
2
θ
h
i
γ rs ¼ À2 E xx À E yy
À
Á
sin θ cos θ þ γ XY cos
2
θ À sin
2
θ
À
Á
2.7.3 Small Strain and Rotation in 3-D
Using the derivation we used for 2-D case, we can derive the formulation for threedimensional case. In the dimensions, we will use u for displacement along x, v for
displacement along y, and w for displacement along z axis. r axis is again our local
(material) coordinate axis:
A
B
D
C
C’
θ
β
α
Fig. 2.27 Relations between local (material) and spatial coordinates
40
2 Stress and Strain in Continuum