

C
p
¼ F
p
T F
p
¼ U
p U
p
ð7:26Þ
B
p
À1 ¼ F
p
ÀT F
p
À1 ¼ V
p
À1 V
p
À1
ð7:27Þ
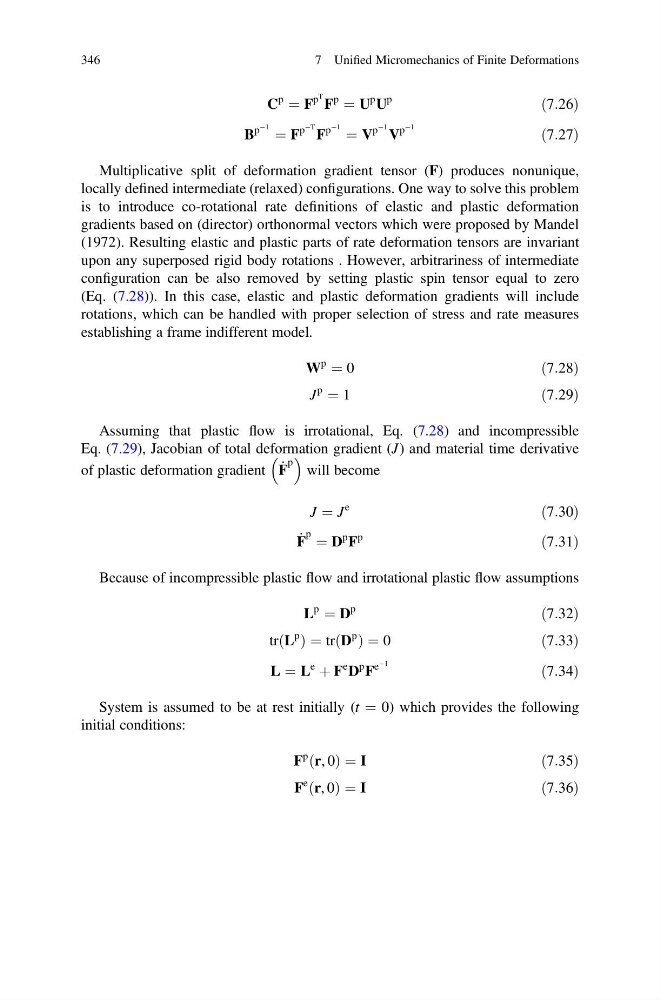
Multiplicative split of deformation gradient tensor (F) produces nonunique,
locally defined intermediate (relaxed) configurations. One way to solve this problem
is to introduce co-rotational rate definitions of elastic and plastic deformation
gradients based on (director) orthonormal vectors which were proposed by Mandel
(1972). Resulting elastic and plastic parts of rate deformation tensors are invariant
upon any superposed rigid body rotations . However, arbitrariness of intermediate
configuration can be also removed by setting plastic spin tensor equal to zero
(Eq. (7.28)). In this case, elastic and plastic deformation gradients will include
rotations, which can be handled with proper selection of stress and rate measures
establishing a frame indifferent model.
W
p
¼ 0
ð7:28Þ
J
p
¼ 1
ð7:29Þ
Assuming that plastic flow is irrotational, Eq. (7.28) and incompressible
Eq. (7.29), Jacobian of total deformation gradient (J) and material time derivative
of plastic deformation gradient _
F
p
will become
J ¼ J
e
ð7:30Þ
_
F
p ¼ D
p F
p
ð7:31Þ
Because of incompressible plastic flow and irrotational plastic flow assumptions
L
p
¼ D
p
ð7:32Þ
tr L
p
ð Þ ¼ tr D
p
ð Þ ¼ 0
ð7:33Þ
L ¼ L
e
þ F
e D
p F
e
À1
ð7:34Þ
System is assumed to be at rest initially (t ¼ 0) which provides the following
initial conditions:
F
p r, 0
ð Þ ¼ I
ð7:35Þ
F
e r, 0
ð Þ ¼ I
ð7:36Þ
346
7 Unified Micromechanics of Finite Deformations
p
¼ F
p
T F
p
¼ U
p U
p
ð7:26Þ
B
p
À1 ¼ F
p
ÀT F
p
À1 ¼ V
p
À1 V
p
À1
ð7:27Þ
Multiplicative split of deformation gradient tensor (F) produces nonunique,
locally defined intermediate (relaxed) configurations. One way to solve this problem
is to introduce co-rotational rate definitions of elastic and plastic deformation
gradients based on (director) orthonormal vectors which were proposed by Mandel
(1972). Resulting elastic and plastic parts of rate deformation tensors are invariant
upon any superposed rigid body rotations . However, arbitrariness of intermediate
configuration can be also removed by setting plastic spin tensor equal to zero
(Eq. (7.28)). In this case, elastic and plastic deformation gradients will include
rotations, which can be handled with proper selection of stress and rate measures
establishing a frame indifferent model.
W
p
¼ 0
ð7:28Þ
J
p
¼ 1
ð7:29Þ
Assuming that plastic flow is irrotational, Eq. (7.28) and incompressible
Eq. (7.29), Jacobian of total deformation gradient (J) and material time derivative
of plastic deformation gradient _
F
p
will become
J ¼ J
e
ð7:30Þ
_
F
p ¼ D
p F
p
ð7:31Þ
Because of incompressible plastic flow and irrotational plastic flow assumptions
L
p
¼ D
p
ð7:32Þ
tr L
p
ð Þ ¼ tr D
p
ð Þ ¼ 0
ð7:33Þ
L ¼ L
e
þ F
e D
p F
e
À1
ð7:34Þ
System is assumed to be at rest initially (t ¼ 0) which provides the following
initial conditions:
F
p r, 0
ð Þ ¼ I
ð7:35Þ
F
e r, 0
ð Þ ¼ I
ð7:36Þ
346
7 Unified Micromechanics of Finite Deformations