

88
4 Multi-Degree of Freedom (MDOF) Systems
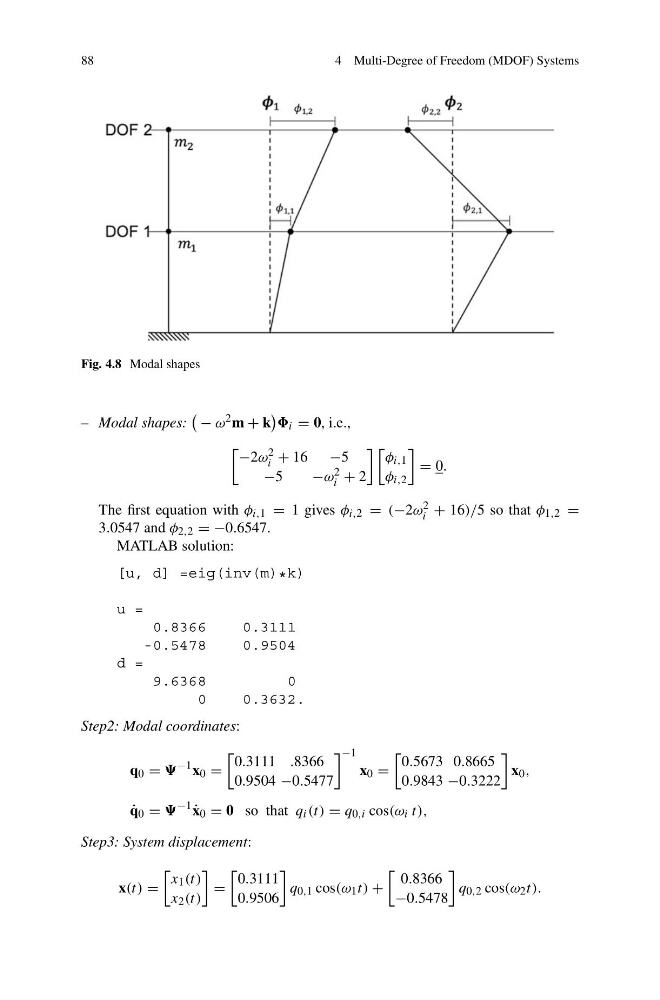
Fig. 4.8 Modal shapes
– Modal shapes:
− ω 2 m + k
i = 0, i.e.,
−2ω 2
i + 16 −5
−5
−ω 2
i + 2
φ i,1
φ i,2
= 0.
The first equation with φ i,1 = 1 gives φ i,2 = (−2ω 2
i + 16)/5 so that φ 1,2 =
3.0547 and φ 2,2 = −0.6547.
MATLAB solution:
[u, d] =eig(inv(m) * k)
u =
0.8366
0.3111
-0.5478
0.9504
d =
9.6368
0
0
0.3632.
Step2: Modal coordinates:
q 0 =
−1 x 0 =
0.3111 .8366
0.9504 −0.5477
−1
x 0 =
0.5673 0.8665
0.9843 −0.3222
x 0 ,
˙
q 0 =
−1
˙
x 0 = 0 so that q i (t) = q 0,i cos(ω i t),
Step3: System displacement:
x(t) =
x 1 (t)
x 2 (t)
=
0.3111
0.9506
q 0,1 cos(ω 1 t) +
0.8366
−0.5478
q 0,2 cos(ω 2 t).