

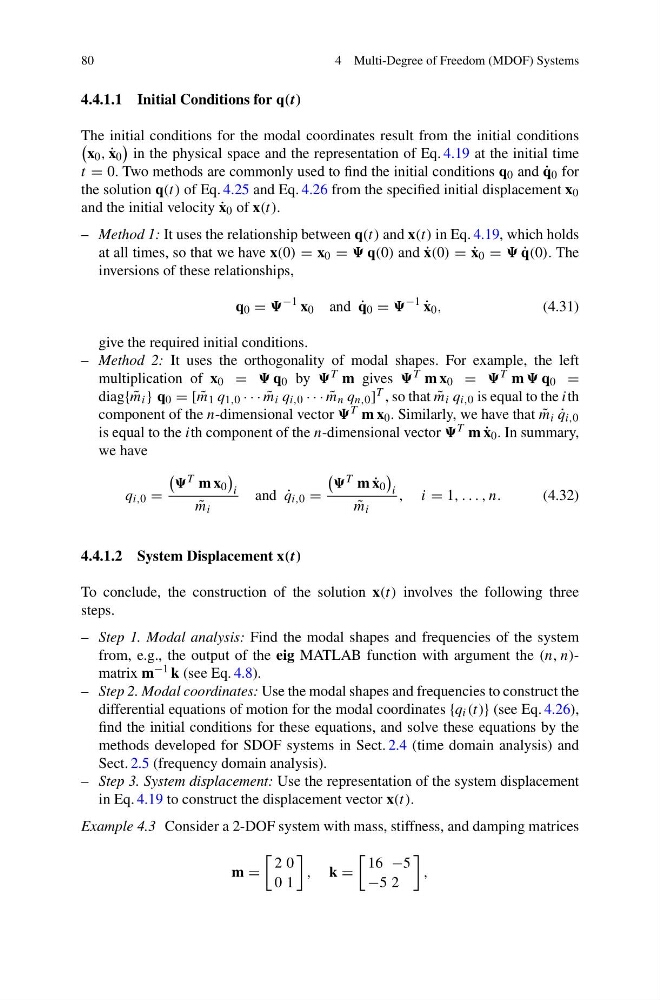
80
4 Multi-Degree of Freedom (MDOF) Systems
4.4.1.1 Initial Conditions for q(t)
The initial conditions for the modal coordinates result from the initial conditions
x 0 , ˙
x 0
in the physical space and the representation of Eq. 4.19 at the initial time
t = 0. Two methods are commonly used to find the initial conditions q 0 and ˙
q 0 for
the solution q(t) of Eq. 4.25 and Eq. 4.26 from the specified initial displacement x 0
and the initial velocity ˙
x 0 of x(t).
– Method 1: It uses the relationship between q(t) and x(t) in Eq. 4.19, which holds
at all times, so that we have x(0) = x 0 = q(0) and ˙
x(0) = ˙
x 0 = ˙
q(0). The
inversions of these relationships,
q 0 =
−1 x 0 and ˙
q 0 =
−1
˙
x 0 ,
(4.31)
give the required initial conditions.
– Method 2: It uses the orthogonality of modal shapes. For example, the left
multiplication of x 0 = q 0 by T m gives T m x 0 = T m q 0 =
diag{ ˜
m i } q 0 = [ ˜
m 1 q 1,0 · · · ˜
m i q i,0 · · · ˜
m n q n,0 ] T , so that ˜
m i q i,0 is equal to the ith
component of the n-dimensional vector T m x 0 . Similarly, we have that ˜
m i ˙
q i,0
is equal to the ith component of the n-dimensional vector T m ˙
x 0 . In summary,
we have
q i,0 =
T m x 0
i
˜
m i
and ˙
q i,0 =
T m ˙
x 0
i
˜
m i
, i = 1, . . . , n.
(4.32)
4.4.1.2 System Displacement x(t)
To conclude, the construction of the solution x(t) involves the following three
steps.
– Step 1. Modal analysis: Find the modal shapes and frequencies of the system
from, e.g., the output of the eig MATLAB function with argument the (n, n)matrix m −1 k (see Eq. 4.8).
– Step 2. Modal coordinates: Use the modal shapes and frequencies to construct the
differential equations of motion for the modal coordinates {q i (t)} (see Eq. 4.26),
find the initial conditions for these equations, and solve these equations by the
methods developed for SDOF systems in Sect. 2.4 (time domain analysis) and
Sect. 2.5 (frequency domain analysis).
– Step 3. System displacement: Use the representation of the system displacement
in Eq. 4.19 to construct the displacement vector x(t).
Example 4.3 Consider a 2-DOF system with mass, stiffness, and damping matrices
m =
2 0
0 1
, k =
16 −5
−5 2
,