

68
4 Multi-Degree of Freedom (MDOF) Systems
4.1 Physical System
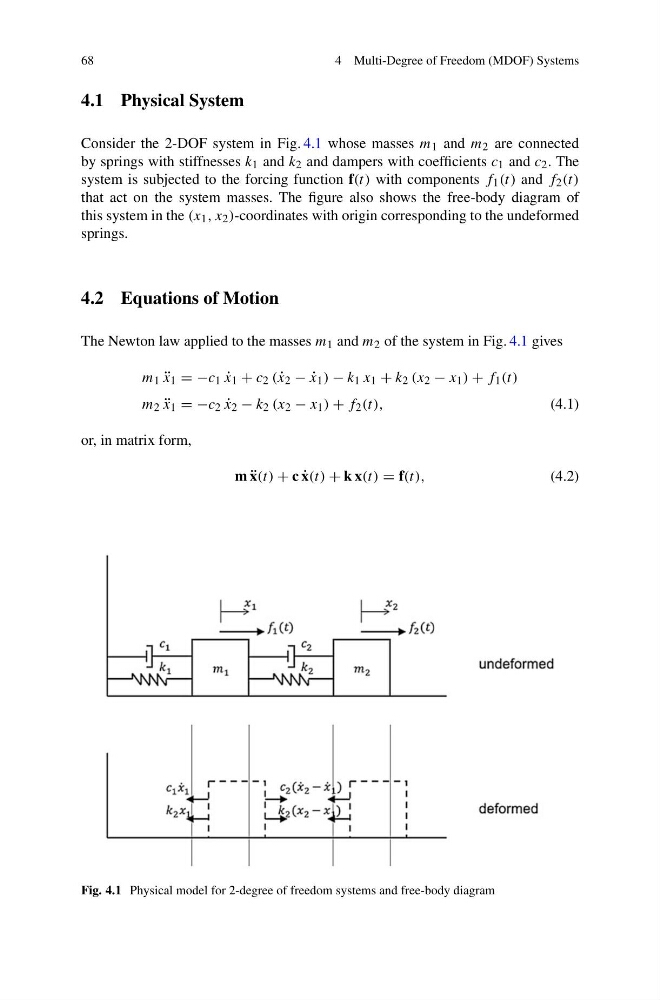
Consider the 2-DOF system in Fig. 4.1 whose masses m 1 and m 2 are connected
by springs with stiffnesses k 1 and k 2 and dampers with coefficients c 1 and c 2 . The
system is subjected to the forcing function f(t) with components f 1 (t) and f 2 (t)
that act on the system masses. The figure also shows the free-body diagram of
this system in the (x 1 , x 2 )-coordinates with origin corresponding to the undeformed
springs.
4.2 Equations of Motion
The Newton law applied to the masses m 1 and m 2 of the system in Fig. 4.1 gives
m 1 ¨
x 1 = −c 1 ˙
x 1 + c 2 ( ˙
x 2 − ˙
x 1 ) − k 1 x 1 + k 2 (x 2 − x 1 ) + f 1 (t)
m 2 ¨
x 1 = −c 2 ˙
x 2 − k 2 (x 2 − x 1 ) + f 2 (t),
(4.1)
or, in matrix form,
m ¨
x(t) + c ˙
x(t) + k x(t) = f(t),
(4.2)
Fig. 4.1 Physical model for 2-degree of freedom systems and free-body diagram