

64
S. Goto and H. Hino
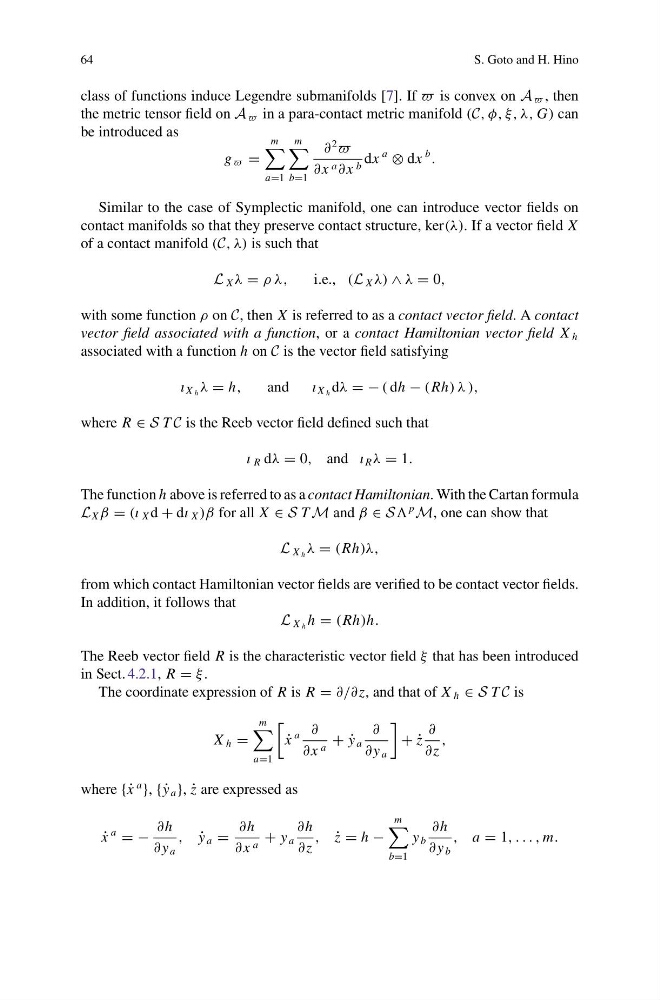
class of functions induce Legendre submanifolds [7]. If is convex on A , then
the metric tensor field on A in a para-contact metric manifold (C, φ, ξ, λ, G) can
be introduced as
g =
m
a=1
m
b=1
∂
2
∂ x a ∂ x b dx
a
⊗ dx
b
.
Similar to the case of Symplectic manifold, one can introduce vector fields on
contact manifolds so that they preserve contact structure, ker(λ). If a vector field X
of a contact manifold (C, λ) is such that
L X λ = ρ λ,
i.e., (L X λ) ∧ λ = 0,
with some function ρ on C, then X is referred to as a contact vector field. A contact
vector field associated with a function, or a contact Hamiltonian vector field X h
associated with a function h on C is the vector field satisfying
ı X h λ = h,
and
ı X h dλ = − ( dh − (Rh) λ ),
where R ∈ S T C is the Reeb vector field defined such that
ı R dλ = 0, and ı R λ = 1.
The function h above is referred to as a contact Hamiltonian. With the Cartan formula
L X β = (ı X d + dı X )β for all X ∈ S T M and β ∈ S
p
M, one can show that
L X h λ = (Rh)λ,
from which contact Hamiltonian vector fields are verified to be contact vector fields.
In addition, it follows that
L X h h = (Rh)h.
The Reeb vector field R is the characteristic vector field ξ that has been introduced
in Sect. 4.2.1, R = ξ .
The coordinate expression of R is R = ∂/∂z, and that of X h ∈ S T C is
X h =
m
a=1
˙
x
a ∂
∂ x a + ˙
y a
∂
∂ y a
+ ˙
z
∂
∂z
,
where { ˙
x
a
}, { ˙
y a }, ˙
z are expressed as
˙
x
a
= −
∂h
∂ y a
, ˙
y a =
∂h
∂ x a + y a
∂h
∂z
, ˙
z = h −
m
b=1
y b
∂h
∂ y b
, a = 1, . . . , m.