

7 On Geodesic Triangles with Right Angles in a Dually Flat Space
165
An important consequence of the coupling of the dual connections to the metric is
that the dual parallel transport preserves the metric.
Let us choose by convention to fix the primal basis of the tangent vectors at T p
for any p ∈ M to be the e i ’s, the one-hot vectors in the θ -coordinate system, i.e.,
e i = (0, . . . , 0
i−1
, 1, 0, . . . , 0) (the standard basis of R
D ). This is the canonical basis.
5
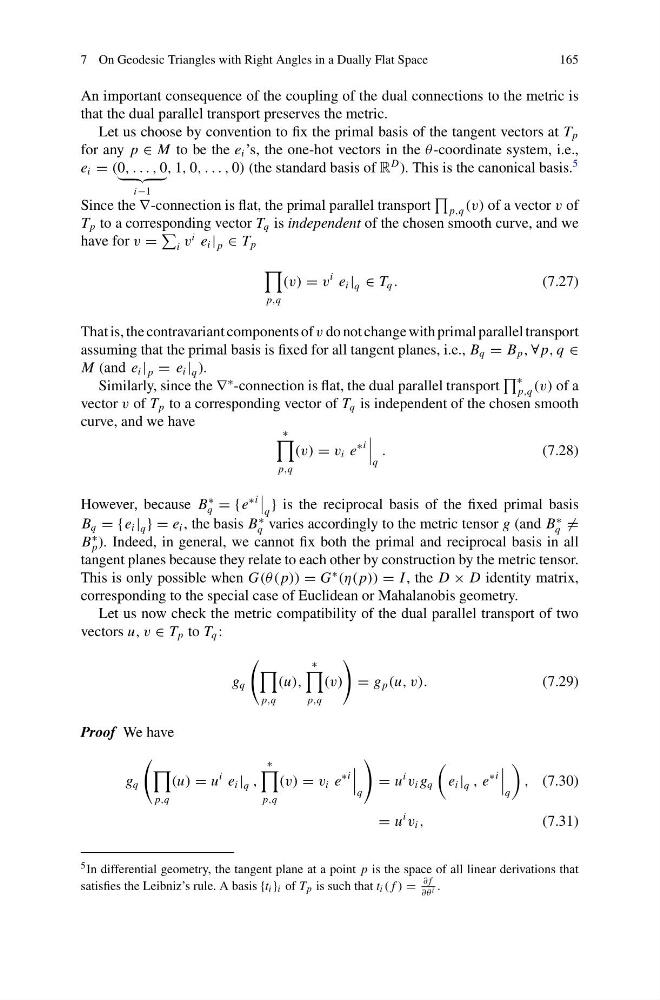
Since the ∇-connection is flat, the primal parallel transport
p,q (v) of a vector v of
T p to a corresponding vector T q is independent of the chosen smooth curve, and we
have for v =
i v
i e i | p ∈ T p
p,q
(v) = v
i e i | q ∈ T q .
(7.27)
That is, the contravariant components of v do not change with primal parallel transport
assuming that the primal basis is fixed for all tangent planes, i.e., B q = B p , ∀ p, q ∈
M (and e i | p = e i | q ).
Similarly, since the ∇
∗ -connection is flat, the dual parallel transport
∗
p,q (v) of a
vector v of T p to a corresponding vector of T q is independent of the chosen smooth
curve, and we have
∗
p,q
(v) = v i e
∗i
q
.
(7.28)
However, because B
∗
q = {e
∗i
q
} is the reciprocal basis of the fixed primal basis
B q = {e i | q } = e i , the basis B
∗
q varies accordingly to the metric tensor g (and B
∗
q =
B
∗
p ). Indeed, in general, we cannot fix both the primal and reciprocal basis in all
tangent planes because they relate to each other by construction by the metric tensor.
This is only possible when G(θ ( p)) = G
∗
(η( p)) = I , the D × D identity matrix,
corresponding to the special case of Euclidean or Mahalanobis geometry.
Let us now check the metric compatibility of the dual parallel transport of two
vectors u, v ∈ T p to T q :
g q
p,q
(u),
∗
p,q
(v)
= g p (u, v).
(7.29)
Proof We have
g q
p,q
(u) = u
i e i | q ,
∗
p,q
(v) = v i e
∗i
q
= u
i
v i g q
e i | q , e
∗i
q
, (7.30)
= u
i
v i ,
(7.31)
5 In differential geometry, the tangent plane at a point p is the space of all linear derivations that
satisfies the Leibniz’s rule. A basis {t i } i of T p is such that t i ( f ) =
∂ f
∂θ i .