

78
Biologically Inspired Robotics
1000
Angle (deg)
800
600
400
200
0
0
0.5
1
1.5
θ 1 Real angle of joint 1
θ 2 Real angle of joint 2
Downswing
Backswing
Followthrough
t t = 0.58
t m = 1.00
t f = 1.43
Time (s)
(a)
–20
–10
0
10
20
30
40
50
60
70
Angular Velocity (rad/s)
dθ 1 /dt Real angular volocity of joint 1
dθ 2 /dt Real angular velocity of joint 2
Downswing
Backswing
Followthrough
t t = 0.58
t m = 1.00
t f = 1.43
0
0.2
0.4
0.6
0.8
1
1.2
1.4
1.6
Time (s)
(b)
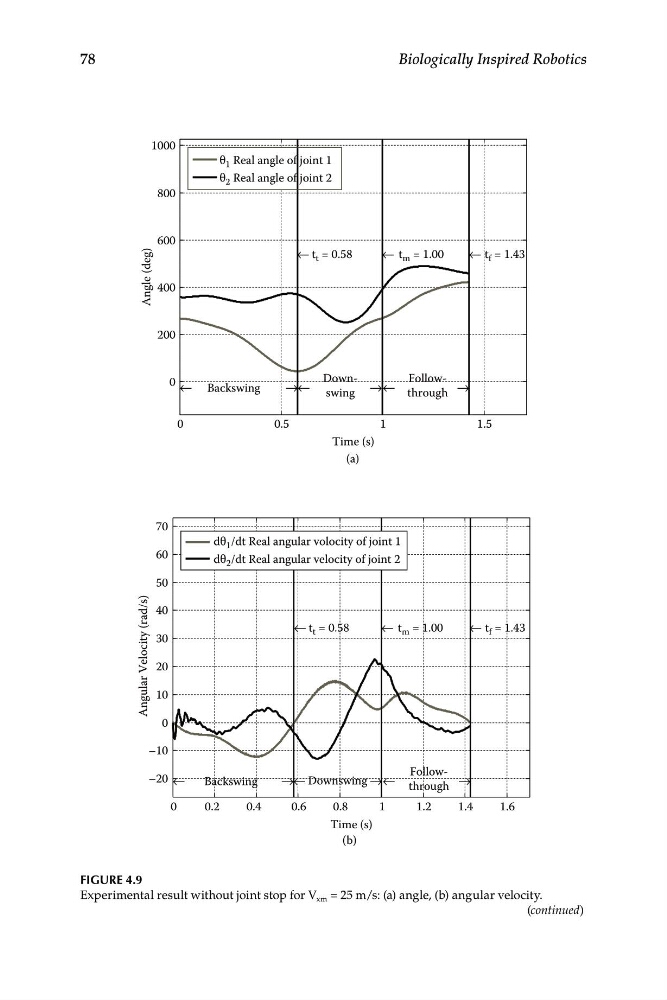
FIGURE 4.9
Experimental result without joint stop for V xm = 25 m/s: (a) angle, (b) angular velocity.
(continued)