

71
Human-Inspired Hyper Dynamic Manipulation
60 (deg)
Arm
Golf club
l 2
Y 0
X 0
τ 1
τ 2
θ 1
θ 2
l 1
Stop
m 2 , l g2 , I 2
m 1 , l g1 , I 1
Swing Plane
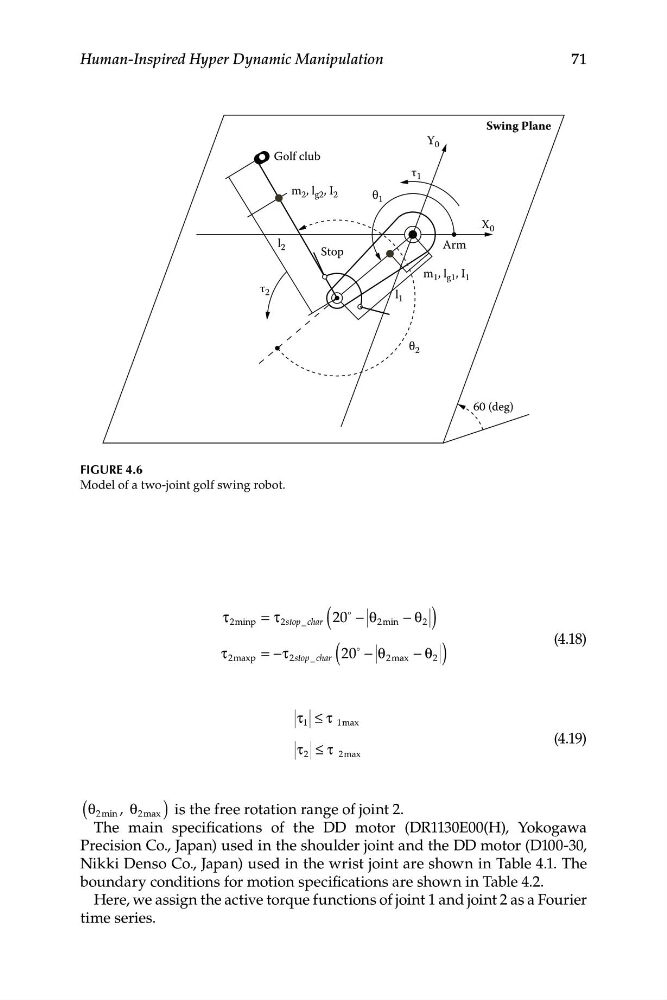
FIGURE 4.6
Model of a two-joint golf swing robot.
τ 2minp = τ
K
2stop _ char ( 20 − θ 2min − θ 2 )
τ
= −τ
(
(4.18)
20
K
2maxp
2 st t op _ char
− θ 2max − θ 2 )
τ 1 ≤ τ 1 max
(4.19)
τ 2 ≤ τ 2max
(θ2min , θ 2max ) is the free rotation range of joint 2.
The main specifications of the DD motor (DR1130E00(H), Yokogawa
Precision Co., Japan) used in the shoulder joint and the DD motor (D100-30,
Nikki Denso Co., Japan) used in the wrist joint are shown in Table 4.1. The
boundary conditions for motion specifications are shown in Table 4.2.
Here, we assign the active torque functions of joint 1 and joint 2 as a Fourier
time series.