

TABLE 3.1
Main Exercise Modes of the Bio-Cycle
Exercise Mode
Ride Mode
Trained Muscles
One drive
The user can exercise only with a hand
or leg
Two drive
Alternate riding: Just like a traditional
Gastrocnemius, gluteus, rectus
bike, the user exercises with the feet at
femoris, and biceps femoris
a 180-degree angle
muscles
Stair-climbing: The user does a
Gluteus and rectus femoris
treading exercise with one leg, and
muscles
the other leg can relax
Cheetah-like walking: The user
exercises by using either hand and
foot alternately
Four drive
The user exercises with both hands and
Gastrocnemius, gluteus, rectus
(bionic
legs at the same time
femoris, biceps femoris,
riding)
abdomen, and upper limb
muscles
38
Biologically Inspired Robotics
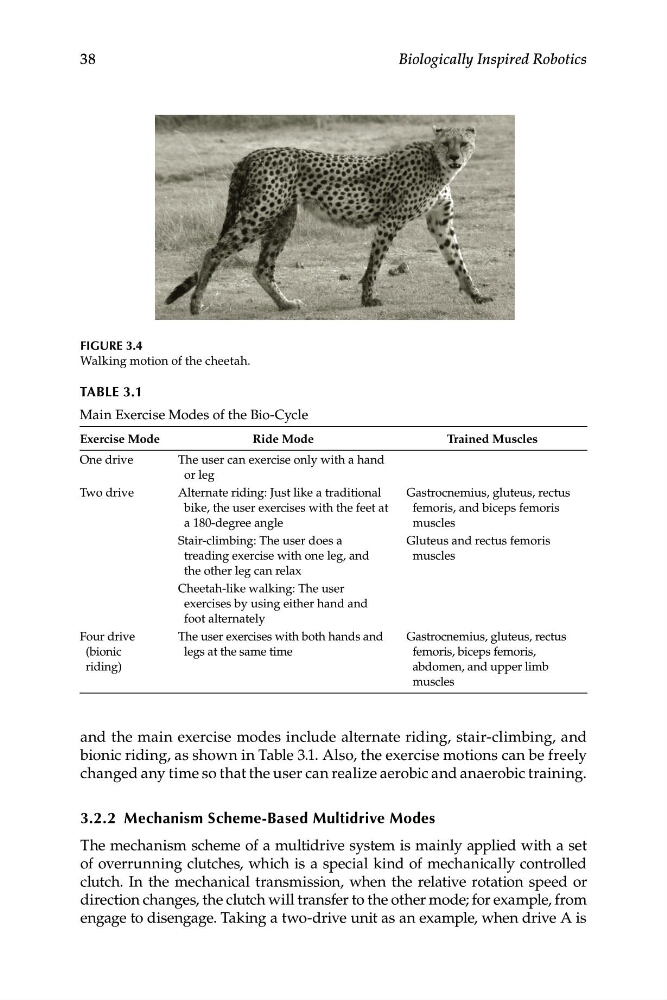
FIGURE 3.4
Walking motion of the cheetah.
and the main exercise modes include alternate riding, stair-climbing, and
bionic riding, as shown in Table 3.1. Also, the exercise motions can be freely
changed any time so that the user can realize aerobic and anaerobic training.
3.2.2 Mechanism Scheme-Based Multidrive Modes
The mechanism scheme of a multidrive system is mainly applied with a set
of overrunning clutches, which is a special kind of mechanically controlled
clutch. In the mechanical transmission, when the relative rotation speed or
direction changes, the clutch will transfer to the other mode; for example, from
engage to disengage. Taking a two-drive unit as an example, when drive A is