

MCU
H8/3694F
SCL
SDA
Servo
PWM
I
2 C Bus
MCU
H8/3694F
SCL
SDA
Servo
PWM
MCU
H8/3694F
SCL
SDA
Servo
PWM
Address
Address
Address
…
RS232
Wireless
module
ID:0×10
ID:0×20
ID:0×30
28
Biologically Inspired Robotics
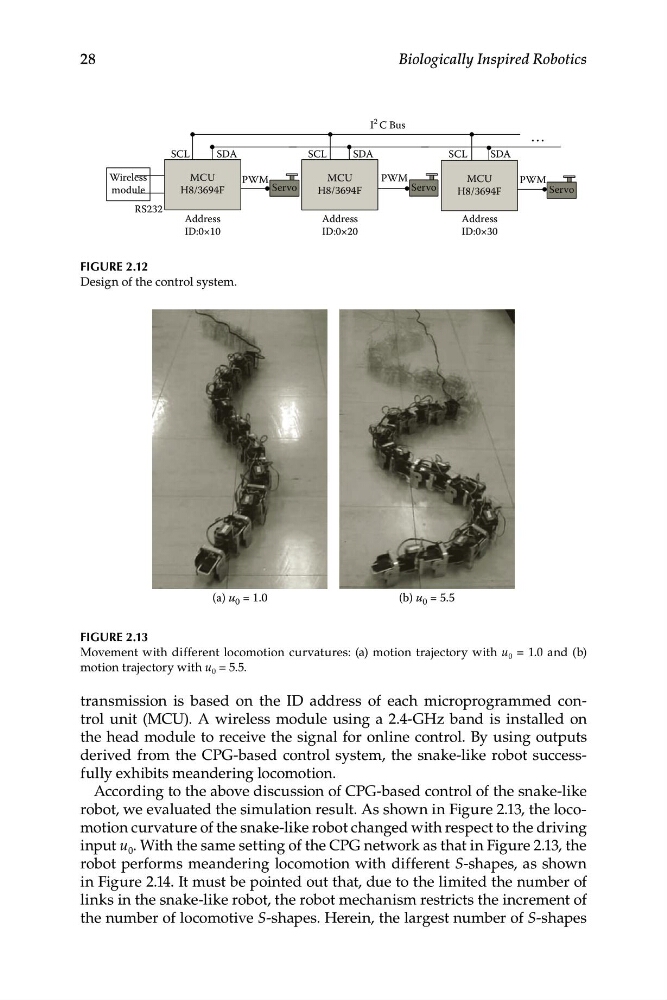
FIGURE 2.12
Design of the control system.
(a) u 0 = 1.0
(b) u 0 = 5.5
FIGURE 2.13
Movement with different locomotion curvatures: (a) motion trajectory with u 0 = 1.0 and (b)
motion trajectory with u 0 = 5.5.
transmission is based on the ID address of each microprogrammed control unit (MCU). A wireless module using a 2.4-GHz band is installed on
the head module to receive the signal for online control. By using outputs
derived from the CPG-based control system, the snake-like robot successfully exhibits meandering locomotion.
According to the above discussion of CPG-based control of the snake-like
robot, we evaluated the simulation result. As shown in Figure 2.13, the locomotion curvature of the snake-like robot changed with respect to the driving
input u 0 . With the same setting of the CPG network as that in Figure 2.13, the
robot performs meandering locomotion with different S-shapes, as shown
in Figure 2.14. It must be pointed out that, due to the limited the number of
links in the snake-like robot, the robot mechanism restricts the increment of
the number of locomotive S-shapes. Herein, the largest number of S-shapes
H8/3694F
SCL
SDA
Servo
PWM
I
2 C Bus
MCU
H8/3694F
SCL
SDA
Servo
PWM
MCU
H8/3694F
SCL
SDA
Servo
PWM
Address
Address
Address
…
RS232
Wireless
module
ID:0×10
ID:0×20
ID:0×30
28
Biologically Inspired Robotics
FIGURE 2.12
Design of the control system.
(a) u 0 = 1.0
(b) u 0 = 5.5
FIGURE 2.13
Movement with different locomotion curvatures: (a) motion trajectory with u 0 = 1.0 and (b)
motion trajectory with u 0 = 5.5.
transmission is based on the ID address of each microprogrammed control unit (MCU). A wireless module using a 2.4-GHz band is installed on
the head module to receive the signal for online control. By using outputs
derived from the CPG-based control system, the snake-like robot successfully exhibits meandering locomotion.
According to the above discussion of CPG-based control of the snake-like
robot, we evaluated the simulation result. As shown in Figure 2.13, the locomotion curvature of the snake-like robot changed with respect to the driving
input u 0 . With the same setting of the CPG network as that in Figure 2.13, the
robot performs meandering locomotion with different S-shapes, as shown
in Figure 2.14. It must be pointed out that, due to the limited the number of
links in the snake-like robot, the robot mechanism restricts the increment of
the number of locomotive S-shapes. Herein, the largest number of S-shapes