

27
CPG-Based Control of Serpentine Locomotion of a Snake-Like Robot
A
B
Joint
angle
Time
…
A
B
Joint 1
Joint 2
(a)
(b)
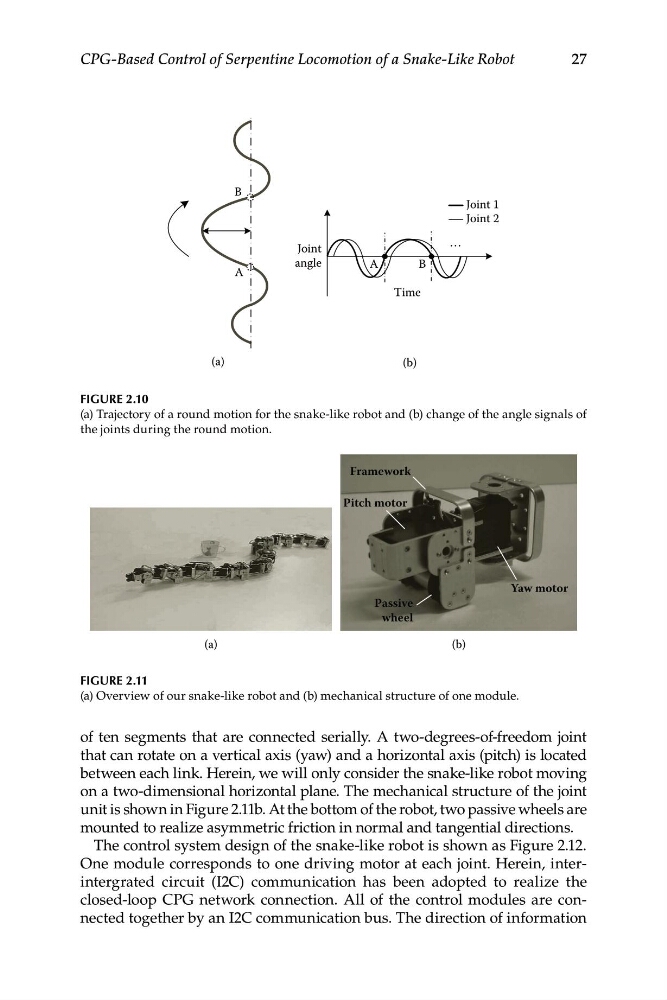
FIGURE 2.10
(a) Trajectory of a round motion for the snake-like robot and (b) change of the angle signals of
the joints during the round motion.
Framework
Pitch motor
Yaw motor
Passive
wheel
(a)
(b)
FIGURE 2.11
(a) Overview of our snake-like robot and (b) mechanical structure of one module.
of ten segments that are connected serially. A two-degrees-of-freedom joint
that can rotate on a vertical axis (yaw) and a horizontal axis (pitch) is located
between each link. Herein, we will only consider the snake-like robot moving
on a two-dimensional horizontal plane. The mechanical structure of the joint
unit is shown in Figure 2.11b. At the bottom of the robot, two passive wheels are
mounted to realize asymmetric friction in normal and tangential directions.
The control system design of the snake-like robot is shown as Figure 2.12.
One module corresponds to one driving motor at each joint. Herein, interintergrated circuit (I2C) communication has been adopted to realize the
closed-loop CPG network connection. All of the control modules are connected together by an I2C communication bus. The direction of information