

17
CPG-Based Control of Serpentine Locomotion of a Snake-Like Robot
CPG network
1
Movement direction
r
w 1r
w ik
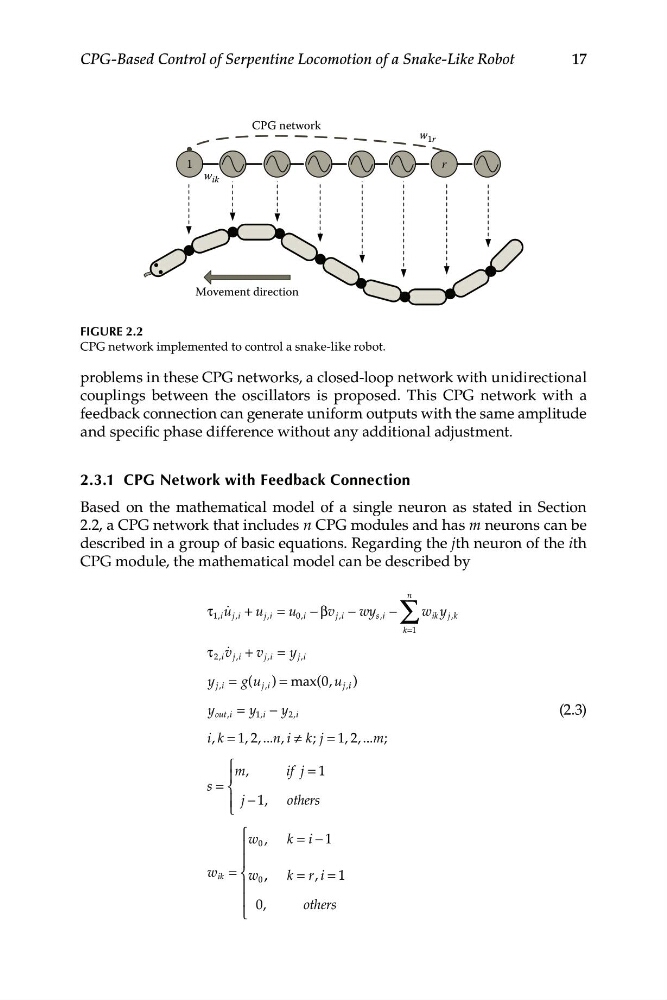
FIGURE 2.2
CPG network implemented to control a snake-like robot.
problems in these CPG networks, a closed-loop network with unidirectional
couplings between the oscillators is proposed. This CPG network with a
feedback connection can generate uniform outputs with the same amplitude
and specific phase difference without any additional adjustment.
2.3.1 CPG Network with Feedback Connection
Based on the mathematical model of a single neuron as stated in Section
2.2, a CPG network that includes n CPG modules and has m neurons can be
described in a group of basic equations. Regarding the jth neuron of the ith
CPG module, the mathematical model can be described by
n
τ 1,i u q j , i + u j , i = u 0,i − βv j i
, − wy s , i − ∑ ∑ w ik y j k
,
k=1
τ 2,i j
v q , i + v j , i = y j , i
y j i
, = g( u j i
, ) = max(0, u j ,i i )
y out , i = y 1,i − y 2,i
(2.3)
i k
, = 1 2
, ,... n, i ≠ k; j = 1 2
, ,.. ..m;
⎧ m,
if j = 1
⎪
s = ⎨
⎪ j − 1, others
⎩
⎧ w
⎪
0 , k = −
i 1
⎪
w ik = ⎨w 0
k r
= ,
i = 1
⎪
⎪ 0,
others
⎩
, ,